“Right High precision, high flexibility, imitation human hand design robot dexterous hand ROHand for Humanoid robot” has been added to your cart. View cart
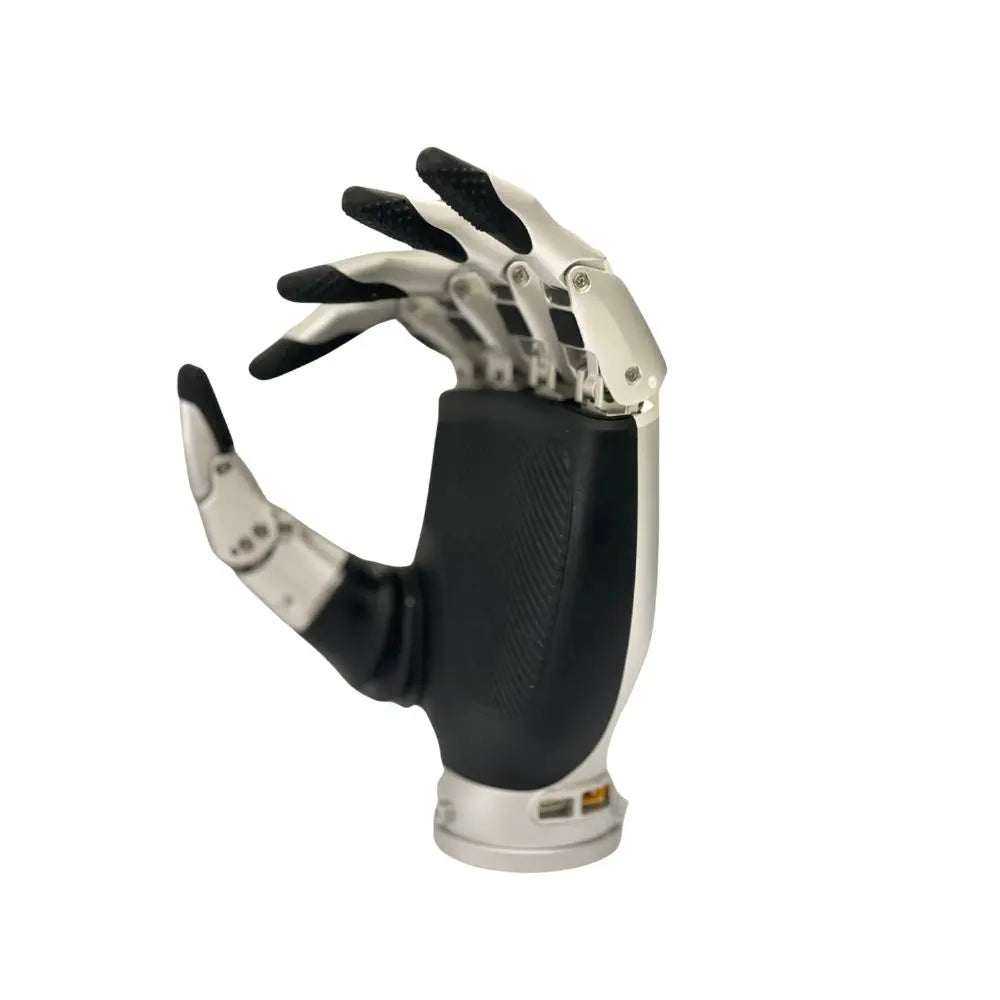
Dexterous Power Humanoid Robot Dexterous Hand (Left)
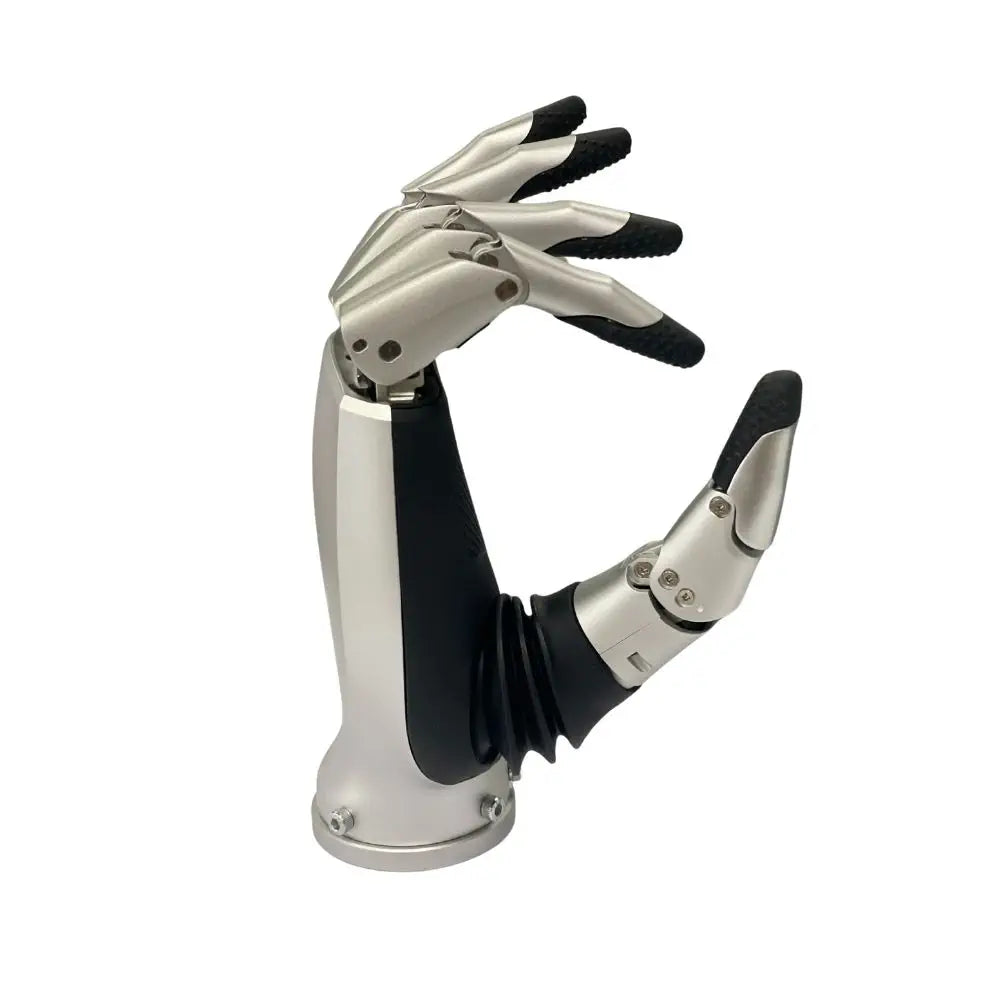
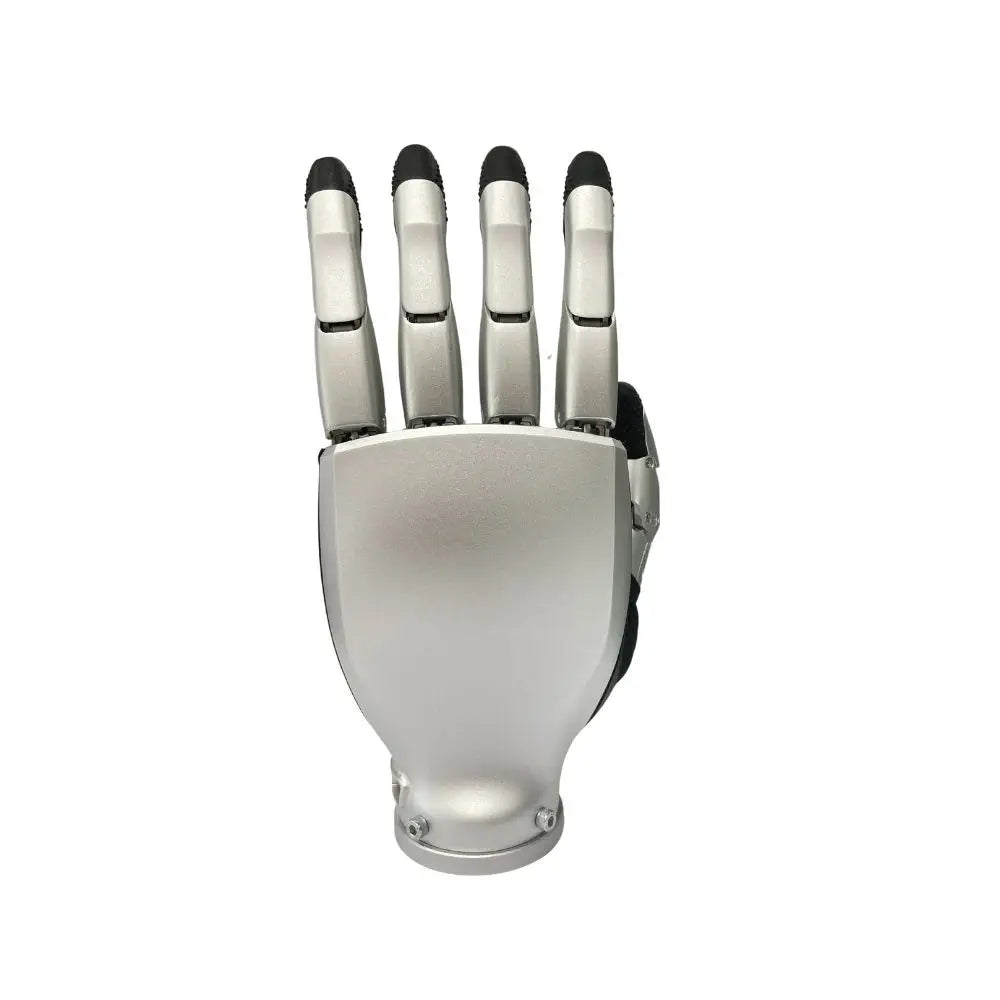
Replicates intricate human hand structure
Excels in high precision and dexterity
Performs complex tasks with ease
Enhances efficiency in industrial automation
Contributes to human-like robot capabilities
The Dexterous Power Humanoid Robot Dexterous Hand (Left) is a sophisticated robotic component engineered to replicate the intricate structure and functionality of the human hand. It excels in high precision and offers multi-degree-of-freedom grasping and manipulation, making it capable of performing complex tasks. These tasks include object gripping, tool usage, and the expression of fine gestures, showcasing its versatility and adaptability in various applications.
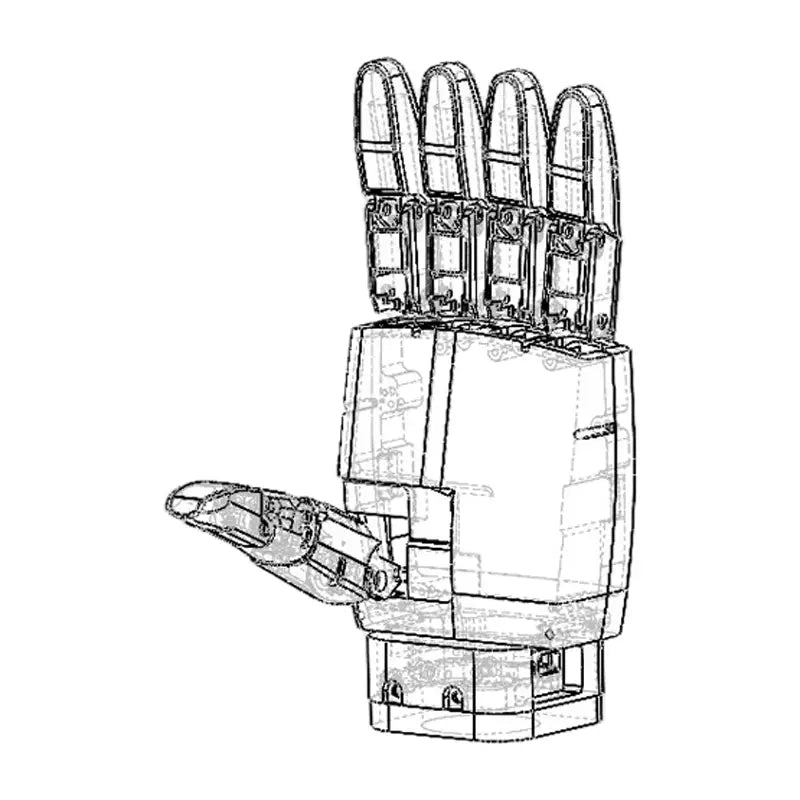
This robotic hand comprises multiple joints, sensors, and actuators, which work harmoniously to achieve its remarkable dexterity and precision. Its design and functionality make it an invaluable asset in fields such as industrial automation, where it can enhance efficiency and precision in manufacturing processes. Additionally, it plays a crucial role in service robotics, contributing to the development of robots that can interact more naturally and effectively with humans.
In the realm of medical assistance, the Humanoid Robot Dexterous Hand represents a significant advancement towards human-like capabilities in robotics. It holds the potential to assist in delicate medical procedures, offering precision and control that can complement human skills. This innovation marks a substantial step forward in the pursuit of creating robots that can seamlessly integrate into human environments and perform tasks with a level of dexterity previously unattainable.
Note: Handle with care to avoid damage to the intricate components.
1x Dexterous Power Humanoid Robot Dexterous Hand (Left)
Degrees of Freedom: 6
Number of Joints: 12
Finger Repeatability Accuracy: 0.5mm ± 0.2mm
Rated Output Force of Thumb: 7N
Rated Output Force of Four Fingers: 7N
Max Output Force of Thumb: 10N
Max Output Force of Four Fingers: 10N
Position Control Resolution: 0.005mm
Thumb Abduction Speed: 78 cm/s
Thumb Flexion Speed: 102 cm/s
Four-Finger Flexion Speed: 102 cm/s
Thumb Abduction Response Time: 0.35 s
Thumb Flexion Response Time: 0.35 s
Four-Finger Flexion Response Time: 0.35 s
Control Interface: EtherCAT
Operating Voltage: 12V
Standby Current: 0.32A
Rated Current: 3A
Max Current: 7.2A
Communication Protocol: EtherCAT
Reviews
There are no reviews yet.
Be the first to review “Dexterous Power Humanoid Robot Dexterous Hand (Left)” Cancel reply








Reviews
There are no reviews yet.