

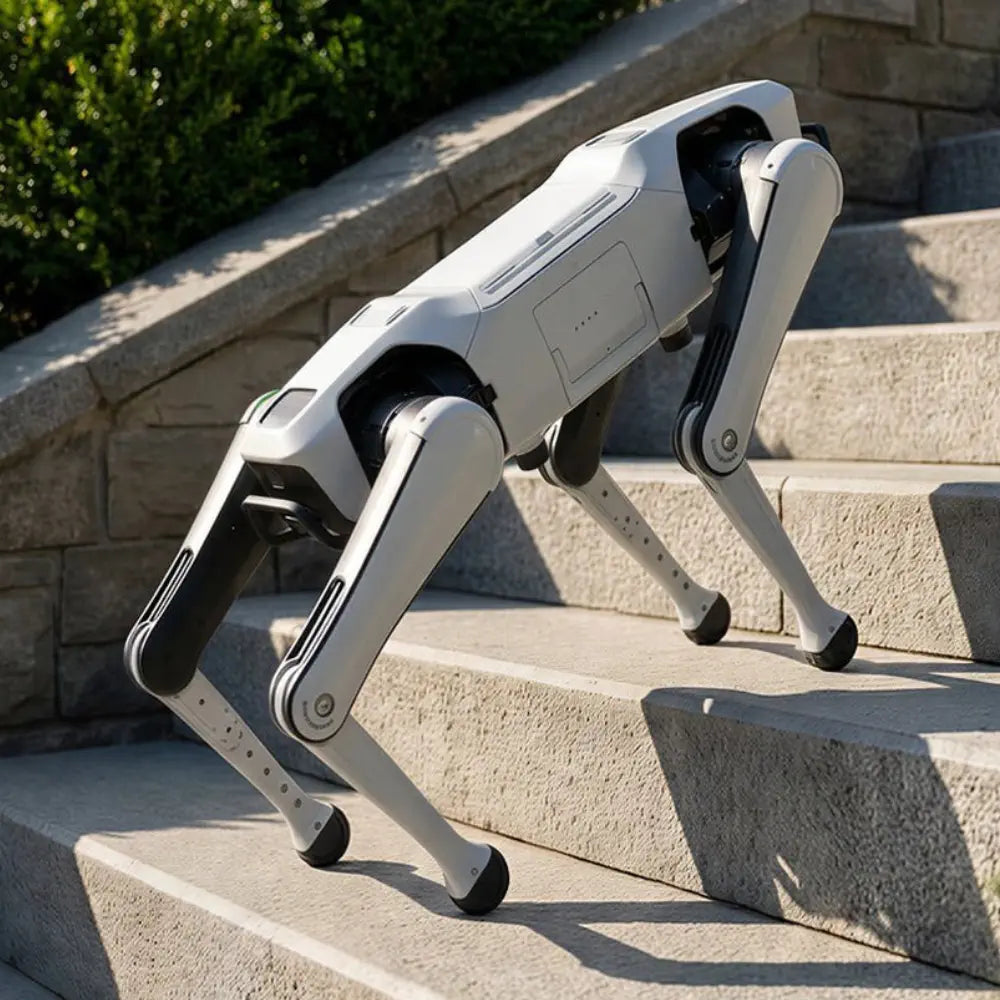
Description
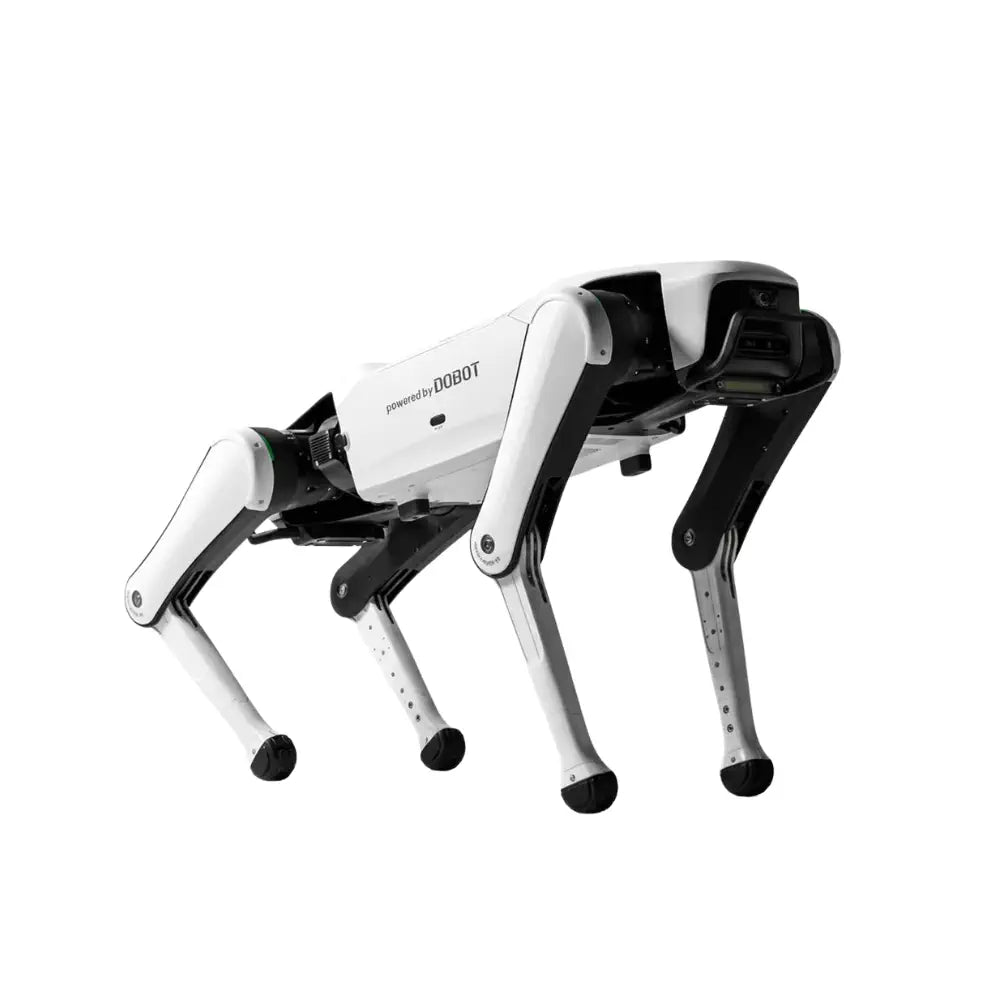
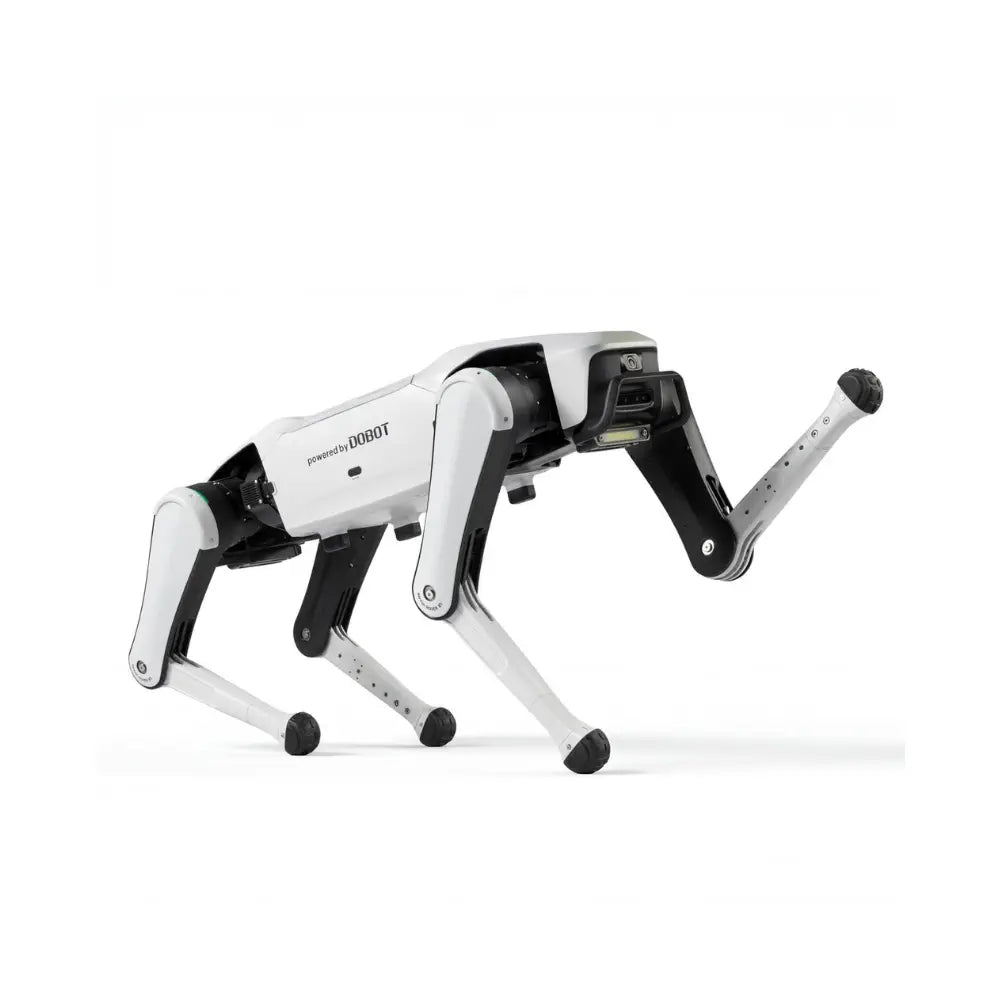
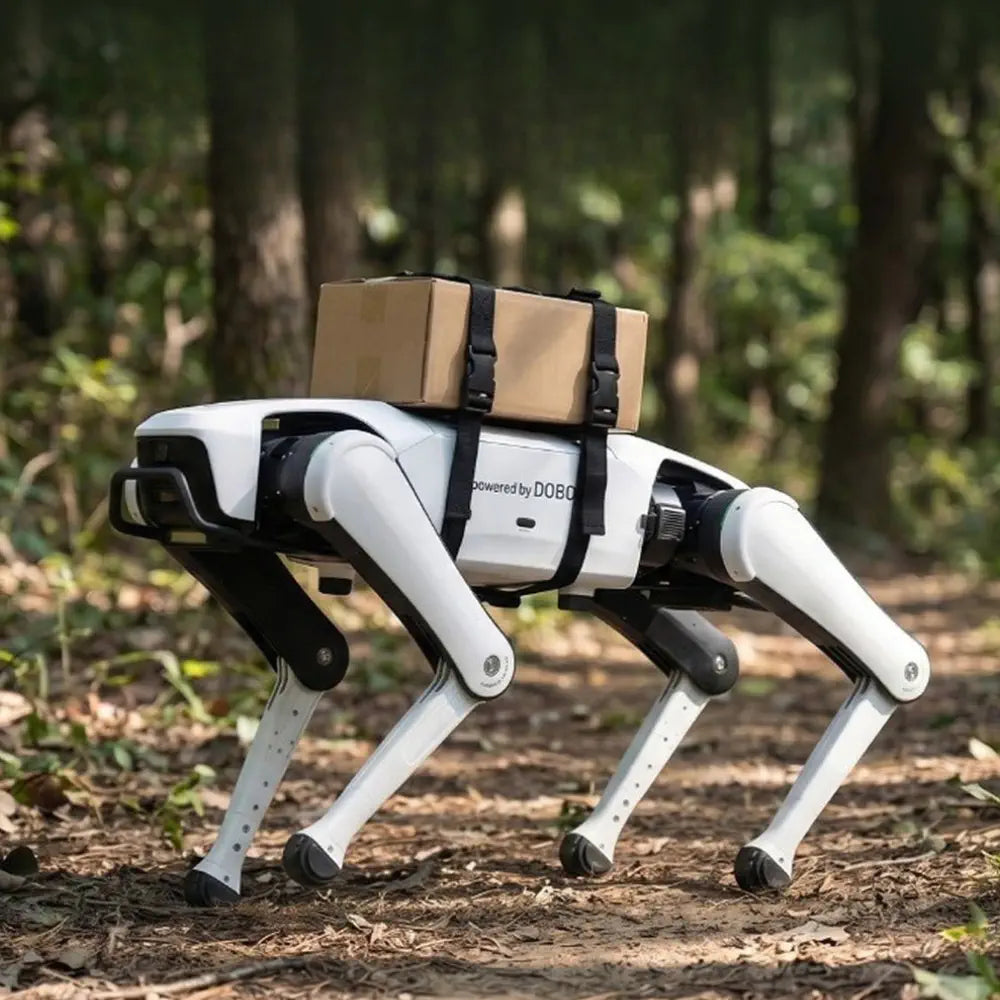
- Dobot Rover X1 Explorer Vision Quadruped Robot
- Bio-inspired point-legged quadruped with 40 TOPS onboard AI compute for advanced perception tasks
- Dual built-in depth cameras plus Intel RealSense D435i for enhanced three-dimensional environmental mapping
- C++ and Python SDK with open low-level and high-level control APIs for secondary development
- Isaac Gym simulation environment support for reinforcement learning and motion research
- Inverted knee joint architecture enhances stair climbing and performance across complex terrain
- Extended 8000 mAh battery delivers approximately 2.5 hours of continuous runtime
Dobot Rover X1 Explorer Vision Quadruped Robot is an education-focused, bio-inspired quadruped platform developed by DOBOT Robotics, built for institutions that require onboard AI compute alongside advanced depth perception. Powered by a 40 TOPS Orin Nano module, the Explorer Vision adds dedicated edge inference capability to the same inverted knee joint architecture that handles terrain ranging from flat indoor floors to 30 to 35-degree inclines and obstacles up to 16 cm in height. Its sensor suite combines front and rear 1080p RGB cameras, dual built-in depth cameras, and an Intel RealSense D435i, giving the platform a richer three-dimensional picture of its surroundings compared to the base Explorer. This expanded perception stack is designed for research teams and institutions developing computer-vision models, sensor fusion pipelines, and machine-perception algorithms that demand higher spatial fidelity.
The platform adopts a layered software interface philosophy, exposing high-level motion control APIs for introductory coursework alongside raw IMU data, joint torque, and MIT-style position-velocity control for advanced research applications. An Enhanced Camera SDK unlocks the full capability of the RealSense D435i alongside the built-in depth cameras, while dual-language AI voice interaction broadens deployment options across multilingual educational environments. Wi-Fi and 4G connectivity, OTA update support, and an open development ecosystem built around C++ and Python SDKs and the Isaac Gym simulation environment allow educators and researchers to customize curriculum, reproduce experiments, and validate algorithms directly on hardware. With an extended 8000 mAh battery, collision protection mechanisms, and a modular payload interface, the Explorer Vision is a capable long-term AI robotics platform for institutions ready to move beyond introductory robotics into applied perception and autonomy research.
background: var(–rsaf-bg,#fff);
border-radius: var(–rsaf-radius,12px);
padding: var(–rsaf-pad,18px);
color: var(–rsaf-tc,#222);
–rsaf-gap: 2px;
}
.rs-section.ai-food-Robqo .cc-heading {
margin: 0 0 10px;
text-align: center;
font-weight: 700;
font-size: clamp(16px, 1.6vw, 20px);
letter-spacing: .15px;
}
.rs-section.ai-food-Robqo .cc-grid {
display: grid;
grid-template-columns: repeat(4, minmax(0, 1fr));
gap: 0;
align-items: stretch;
}
.rs-section.ai-food-Robqo .cc-col {
min-width: 0;
padding: var(–rsaf-col-pad, 12px 16px);
text-align: left;
display: flex;
flex-direction: column;
justify-content: flex-start;
gap: var(–rsaf-gap,2px) !important;
}
.rs-section.ai-food-Robqo .cc-col + .cc-col {
border-left: 1px solid var(–rsaf-sep,#e6e8ee);
}
.rs-section.ai-food-Robqo .cc-row {
display: flex;
align-items: center;
justify-content: flex-start;
gap: 10px;
line-height: 1 !important;
padding: 0 !important;
margin: 0 !important;
min-height: 0 !important;
}
.rs-section.ai-food-Robqo .cc-row img.cc-icon {
width: var(–rsaf-icon,28px);
height: var(–rsaf-icon,28px);
display: block !important;
line-height: 0 !important;
vertical-align: middle !important;
margin: 0 !important;
}
.rs-section.ai-food-Robqo .cc-title {
margin: 0 !important;
padding: 0 !important;
font-weight: 700;
font-size: clamp(13px, 1.05vw, 15px);
line-height: 1.05 !important;
}
.rs-section.ai-food-Robqo p.cc-desc {
margin: 0 !important;
padding: 0 !important;
margin-top: var(–rsaf-gap,2px) !important;
font-size: clamp(11.5px, .95vw, 12.5px);
line-height: 1.3 !important;
color: var(–rsaf-muted,#6f7888);
max-width: 36ch;
}
@media (max-width:900px) {
.rs-section.ai-food-Robqo .cc-grid { grid-template-columns: repeat(2, minmax(0, 1fr)); }
.rs-section.ai-food-Robqo .cc-col + .cc-col { border-left: 0; }
.rs-section.ai-food-Robqo .cc-col { border-top: 1px solid var(–rsaf-sep,#e6e8ee); }
.rs-section.ai-food-Robqo .cc-col:nth-child(1),
.rs-section.ai-food-Robqo .cc-col:nth-child(2) { border-top: 0; }
.rs-section.ai-food-Robqo .cc-col:nth-child(2),
.rs-section.ai-food-Robqo .cc-col:nth-child(4) { border-left: 1px solid var(–rsaf-sep,#e6e8ee); }
.rs-section.ai-food-Robqo p.cc-desc { max-width: 60ch; }
}
@media (max-width:650px) {
.rs-section.ai-food-Robqo .cc-grid { grid-template-columns: 1fr; }
.rs-section.ai-food-Robqo .cc-col {
padding: 12px 12px;
border-left: 0 !important;
border-top: 1px solid var(–rsaf-sep,#e6e8ee);
}
.rs-section.ai-food-Robqo .cc-col:first-child { border-top: 0; }
}

Full manufacturer-backed warranty coverage and dedicated product support

Complete end-to-end logistics management, including customs clearance

All pre-sales and post-sales support handled by our dedicated team

Full access to detailed technical guides and a comprehensive knowledge base
.rs-section.rs-static-hero img {
display: block;
vertical-align: top;
max-width: 100%;
margin: 0;
padding: 0;
border: 0;
}.pwiz-pqg3i .rs-section.rs-static-hero {
position: relative;
overflow: hidden;
border-radius: 18px;
background: #f8f8f8;
color: #ffffff;
width: 100%;
height: 600px;
font-family: ‘Arimo’, Arial, sans-serif;
}.pwiz-pqg3i .rs-section.rs-static-hero .rs-si-img {
position: absolute;
inset: 0;
width: 100%;
height: 100%;
object-fit: cover;
object-position: center;
display: block;
border-radius: 18px;
}.pwiz-pqg3i .rs-section.rs-static-hero .rs-si-wrap {
position: absolute;
inset: 0;
z-index: 2;
max-width: 1200px;
margin: 0 auto;
padding: 80px;
display: flex;
align-items: flex-end;
justify-content: flex-start;
text-align: left;
text-shadow: 0 2px 10px rgba(0,0,0,.55);
pointer-events: none;
}.pwiz-pqg3i .rs-section.rs-static-hero .rs-si-copy { max-width: 60ch; pointer-events: auto; }.pwiz-pqg3i .rs-section.rs-static-hero .rs-si-kicker { margin: 0 0 .5rem !important; font-size: clamp(12px,1.3vw,14px); letter-spacing: .06em; text-transform: uppercase; opacity: .9; font-family: ‘Arimo’, Arial, sans-serif; }.pwiz-pqg3i .rs-section.rs-static-hero .rs-si-title { margin: 0 !important; font-size: clamp(28px,4vw,44px); line-height: 1.1; font-weight: 550; font-family: ‘Poppins’, Arial, sans-serif; }.pwiz-pqg3i .rs-section.rs-static-hero .rs-si-subtitle { margin: .8rem 0 0 !important; font-size: clamp(14px,1.8vw,18px); line-height: 1.35; opacity: .92; font-family: ‘Arimo’, Arial, sans-serif; }
@media (max-width: 900px) {.pwiz-pqg3i .rs-section.rs-static-hero { height: clamp(300px, 60vw, 600px); }
}

.rs-section.rs-stat-highlights img{display:block;vertical-align:top;max-width:100%;margin:0;padding:0;border:0}
.rs-section.rs-stat-highlights{background:transparent;padding:0px;border-radius:0px;font-family:’Arimo’,Arial,sans-serif}
.rs-section.rs-stat-highlights .rs-sh-grid{display:flex;flex-wrap:wrap;justify-content:space-around;gap:24px;text-align:center}
.rs-section.rs-stat-highlights .rs-sh-grid.rs-card-on{background:#ffffff !important;border:1px solid #e6eaf2;padding:32px 20px 32px;border-radius:15px;box-shadow:0 8px 24px -4px rgba(0,0,0,0.12)}
.rs-section.rs-stat-highlights .rs-sh-grid.rs-card-off{background:transparent;padding:20px 0;border-radius:0;box-shadow:none}
.rs-section.rs-stat-highlights .rs-sh-item{flex:1 1 18%;min-width:140px}
.rs-section.rs-stat-highlights .rs-sh-lbl{font-size:11px;font-weight:550;letter-spacing:.08em;text-transform:uppercase;color:#000000;line-height:1.4;margin:0 0 6px}
.rs-section.rs-stat-highlights .rs-sh-val{font-size:40px;font-weight:700;line-height:1.1;margin:0;letter-spacing:-.5px;color:#00446a;text-shadow:0 3px 8px rgba(0,0,0,0.18);font-family:’Poppins’,Arial,sans-serif}
.rs-section.rs-stat-highlights .rs-sh-item:nth-child(n+6){display:none}
@media(max-width:600px){.rs-section.rs-stat-highlights .rs-sh-item{flex:1 1 40%}}
.rs-ep-outer.rs-card-on{background:#f8f8f8;border-radius:15px;padding:0 20px;box-shadow:0 8px 24px -4px rgba(0,0,0,0.12)}
.rs-ep-outer.rs-card-off{background:transparent;box-shadow:none}
.rs-ep-header{text-align:center;padding:0 0 22px;max-width:740px;margin:0 auto}
.rs-ep-header-title{margin:0 0 14px 0 !important;font-family:system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;font-size:clamp(22px,3vw,36px);font-weight:800;line-height:1.1;color:#111}
.rs-ep-header-sub{margin:0 !important;font-family:system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;font-size:clamp(14px,1.6vw,17px);line-height:1.55;color:#444}
.rs-ep-wrap{display:flex;flex-wrap:nowrap;gap:10px;padding:0;align-items:stretch;width:100%;height:var(–ep-h,400px);box-sizing:border-box;line-height:0}
.rs-ep-panel{position:relative;min-width:0;overflow:hidden;border-radius:14px;box-shadow:0 10px 26px rgba(0,0,0,.12);height:100%;display:block;box-sizing:border-box;isolation:isolate;flex:1 1 0%;margin:0 !important;padding:0 !important;border:0 !important;outline:0 !important;background:var(–ep-panel-bg,#222) !important;font-family:system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif}
.rs-ep-panel,.rs-ep-panel *{transition:none !important;animation:none !important;transform:none !important}
.rs-ep-wrap .rs-ep-panel:nth-child(n+4){display:none !important}
.rs-ep-panel .rs-ep-img{position:absolute;inset:0 !important;width:100% !important;height:100% !important;display:block !important;margin:0 !important;padding:0 !important;border:0 !important;object-fit:cover;object-position:center 35%}
.rs-ep-panel::after{content:””;position:absolute;inset:0;z-index:1;pointer-events:none;background:linear-gradient(90deg,rgba(0,0,0,1),rgba(0,0,0,0.3));opacity:var(–ep-shade-c,0.7)}
.rs-ep-panel .rs-ep-collapsed{position:absolute;top:12px;left:12px;right:40px;z-index:2;pointer-events:none;margin:0 !important}
.rs-ep-panel .rs-ep-label{display:block;font-weight:800;font-size:12px;line-height:1.05;letter-spacing:.15px;color:var(–ep-tc,#fff) !important;text-shadow:none;pointer-events:auto}
.rs-ep-panel .rs-ep-arrow{position:absolute;top:0;right:-28px;font-size:18px;line-height:1;color:var(–ep-tc,#fff);opacity:.9;pointer-events:none}
.rs-ep-panel .rs-ep-expanded{position:absolute;inset:0;z-index:2;padding:22px 26px;line-height:normal;display:flex;flex-direction:column;justify-content:var(–ep-valign,flex-start);color:var(–ep-tc,#fff);text-align:left;background:transparent;visibility:hidden;opacity:0;pointer-events:none}
.rs-ep-panel .rs-ep-expanded b{color:var(–ep-tc,#fff)}
.rs-ep-panel .rs-ep-kv{max-width:420px}
.rs-ep-panel .rs-ep-title,.rs-ep-panel .rs-ep-chip,.rs-ep-panel .rs-ep-row,.rs-ep-panel .rs-ep-note{pointer-events:auto}
.rs-ep-panel .rs-ep-title{margin:0 0 14px 0 !important;font-weight:900;font-size:clamp(28px,3.0vw,44px);letter-spacing:-0.3px;line-height:1.02}
.rs-ep-panel .rs-ep-chip{display:inline-block;align-self:flex-start;margin:2px 0 12px 0 !important;padding:6px 10px;border-radius:999px;font-size:12px;font-weight:800}
.rs-ep-panel .rs-ep-row{margin:8px 0 !important;font-size:13px;line-height:1.35}
.rs-ep-panel .rs-ep-note{margin:6px 0 10px 0 !important;font-size:12px;color:rgba(255,255,255,.65)}
.ep-sh-soft .rs-ep-panel .rs-ep-label,.ep-sh-soft .rs-ep-panel .rs-ep-title{text-shadow:0 2px 14px rgba(0,0,0,.55) !important}
.ep-sh-strong .rs-ep-panel .rs-ep-label,.ep-sh-strong .rs-ep-panel .rs-ep-title{text-shadow:0 2px 6px rgba(0,0,0,1),0 0 20px rgba(0,0,0,.85) !important}
.ep-zoom-on .rs-ep-panel .rs-ep-img{transform:scale(1) !important;transition:transform 420ms ease !important}
.rs-ep-panel.is-default{flex:3 1 0%}
.rs-ep-panel.is-default::after{opacity:var(–ep-shade-o,0);background:linear-gradient(90deg,rgba(0,0,0,1),rgba(0,0,0,0.3))}
.rs-ep-panel.is-default .rs-ep-expanded{visibility:visible;opacity:1}
.rs-ep-panel.is-default .rs-ep-collapsed{visibility:hidden;opacity:0;pointer-events:none}
@media (hover:hover) and (pointer:fine){
.rs-ep-panel{transition:flex-grow 420ms ease !important;will-change:flex-grow}
.rs-ep-panel::after{transition:opacity 420ms ease !important}
.rs-ep-panel .rs-ep-expanded,.rs-ep-panel .rs-ep-collapsed{transition:opacity 200ms ease,visibility 200ms ease !important}
.rs-ep-wrap:hover .rs-ep-panel.is-default{flex:1 1 0%}
.rs-ep-wrap:hover .rs-ep-panel.is-default::after{opacity:var(–ep-shade-c,0.7);background:linear-gradient(90deg,rgba(0,0,0,1),rgba(0,0,0,0.3))}
.rs-ep-wrap:hover .rs-ep-panel.is-default .rs-ep-expanded{visibility:hidden;opacity:0;pointer-events:none}
.rs-ep-wrap:hover .rs-ep-panel.is-default .rs-ep-collapsed{visibility:visible;opacity:1}
.rs-ep-wrap:hover .rs-ep-panel:hover{flex:3 1 0%}
.rs-ep-wrap:hover .rs-ep-panel:hover::after{opacity:var(–ep-shade-o,0);background:linear-gradient(90deg,rgba(0,0,0,1),rgba(0,0,0,0.3))}
.rs-ep-wrap:hover .rs-ep-panel:hover .rs-ep-expanded{visibility:visible;opacity:1}
.rs-ep-wrap:hover .rs-ep-panel:hover .rs-ep-collapsed{visibility:hidden;opacity:0;pointer-events:none}
.ep-zoom-on .rs-ep-panel.is-default .rs-ep-img{transform:scale(1.2) !important}
.ep-zoom-on .rs-ep-wrap:hover .rs-ep-panel.is-default .rs-ep-img{transform:scale(1) !important}
.ep-zoom-on .rs-ep-wrap:hover .rs-ep-panel:hover .rs-ep-img{transform:scale(1.2) !important}
}
@media (max-width:650px){
.rs-ep-wrap{flex-direction:column;height:auto;gap:12px}
.rs-ep-panel{height:320px;flex:none !important}
.rs-ep-panel::after{opacity:0 !important;background:none !important}
.rs-ep-panel .rs-ep-expanded{visibility:visible !important;opacity:1 !important}
.rs-ep-panel .rs-ep-kv{flex:1 1 auto;justify-content:center}
.rs-ep-panel .rs-ep-collapsed{display:none !important}
}


.rs-section.rs-card-grid img{display:block;vertical-align:top;max-width:100%;margin:0;padding:0;border:0}
.rs-section.rs-card-grid{border-radius:15px;font-family:’Arimo’,Arial,sans-serif}
.rs-section.rs-card-grid.rs-card-on{background:#f8f8f8;box-shadow:0 8px 24px -4px rgba(0,0,0,0.12)}
.rs-section.rs-card-grid.rs-card-off{background:transparent;box-shadow:none}
.rs-section.rs-card-grid .ti-wrap{max-width:980px;margin:0 auto}
.rs-section.rs-card-grid .ti-head{text-align:center;margin:0 0 22px}
.rs-section.rs-card-grid .ti-head-title{font-size:30px;font-weight:550;margin:0;color:#111827;font-family:’Poppins’,Arial,sans-serif}
.rs-section.rs-card-grid .ti-head p{margin:10px auto 0;max-width:860px;color:#667085;line-height:1.6}
.rs-section.rs-card-grid .ti-grid{display:grid;gap:18px;grid-template-columns:repeat(2,minmax(0,1fr))}
.rs-section.rs-card-grid .ti-card{background:#ffffff !important;border:1px solid #e6eaf2;border-radius:12px;box-shadow:0 10px 24px rgba(17,24,39,.06);padding:22px 24px}
.rs-section.rs-card-grid .ti-card:nth-child(n+6){display:none}
.rs-section.rs-card-grid .ti-icon{width:50px;height:50px;border-radius:9px;background:#eef2ff;display:flex;align-items:center;justify-content:center;margin:0 0 12px}
.rs-section.rs-card-grid .ti-icon img{width:40px;height:40px}
.rs-section.rs-card-grid .ti-title{font-weight:550;color:#111827;margin:0 0 8px;font-family:’Poppins’,Arial,sans-serif}
.rs-section.rs-card-grid .ti-body{margin:0;color:#667085;line-height:1.6}
@media(max-width:768px){.rs-section.rs-card-grid .ti-grid{grid-template-columns:1fr}}

The Explorer supports autonomous following and intelligent obstacle avoidance for untethered operation. Bidirectional detection with auto-braking ensures safe operation in dynamic environments shared with people.

C++ and Python SDKs expose both high-level motion control and low-level joint interfaces, enabling seamless integration with research workflows. Open APIs cover speed control, gait switching, raw IMU data, and MIT-style joint torque commands.

An Isaac Gym simulation environment is provided out of the box, enabling reinforcement learning experiments and motion algorithm validation before deployment on the physical robot. Motion and navigation application examples are also included to accelerate research workflows.

A modular camera mount and multiple expansion interfaces allow researchers to attach additional sensors and custom payloads to the platform. This makes the Explorer compatible with a wide range of experimental configurations and development needs.
.rs-section.rs-staggered-rows img{display:block;vertical-align:top;max-width:100%;margin:0;padding:0;border:0}
.rs-section.rs-staggered-rows{font-family:’Arimo’,Arial,sans-serif;border-radius:15px}
.rs-section.rs-staggered-rows.rs-card-on{background:#f8f8f8;box-shadow:0 8px 24px -4px rgba(0,0,0,0.12)}
.rs-section.rs-staggered-rows.rs-card-off{background:transparent;box-shadow:none}
.rs-section.rs-staggered-rows .inner{max-width:1140px;margin:0 auto}
.rs-section.rs-staggered-rows .hero{text-align:center;border-bottom:1px solid rgba(0,0,0,.08);padding:6px 6px 14px;margin:0 0 26px}
.rs-section.rs-staggered-rows .hero .h{font-size:32px;font-weight:550;margin:0;color:#0b1220;font-family:’Poppins’,Arial,sans-serif}
.rs-section.rs-staggered-rows .hero .p{margin:10px auto 0;max-width:980px;color:rgba(11,18,32,.62);line-height:1.5}
.rs-section.rs-staggered-rows .rows{display:flex;flex-direction:column;gap:26px}
.rs-section.rs-staggered-rows .wma-row{display:flex;align-items:center;gap:26px}
.rs-section.rs-staggered-rows .wma-row.rev{flex-direction:row-reverse}
.rs-section.rs-staggered-rows .rows .wma-row:nth-child(n+6){display:none}
.rs-section.rs-staggered-rows .wma-text{flex:1 1 44%;min-width:0}
.rs-section.rs-staggered-rows .wma-title{display:flex;gap:12px;align-items:flex-start}
.rs-section.rs-staggered-rows .wma-h3{font-size:24px;font-weight:550;margin:0;color:#0b1220;line-height:1.15;font-family:’Poppins’,Arial,sans-serif}
.rs-section.rs-staggered-rows .wma-p{margin:10px 0 0;color:rgba(11,18,32,.62);line-height:1.55}
.rs-section.rs-staggered-rows .wma-media{flex:1 1 56%;min-width:0}
.rs-section.rs-staggered-rows .wma-box{border-radius:14px;overflow:hidden;background:#ffffff !important;aspect-ratio:16/9;position:relative;min-height:160px}
.rs-section.rs-staggered-rows .wma-box img{position:absolute;inset:0;width:100%;height:100%;object-fit:cover;object-position:center;display:block;vertical-align:top}
@media(max-width:780px){
.rs-section.rs-staggered-rows .wma-row,
.rs-section.rs-staggered-rows .wma-row.rev{flex-direction:column!important;gap:16px}
.rs-section.rs-staggered-rows .wma-text,
.rs-section.rs-staggered-rows .wma-media{flex:1 1 auto;width:100%}
}


padding-top:18px;
–inc-bg:#f8f8f8;
–inc-line:rgba(11,18,32,.14);
–inc-txt:#0b1220;
–inc-muted:rgba(11,18,32,.70);
–inc-accent:#00446a;
–inc-radius:15px;
–inc-pad:16px;
–inc-indent:18px;
font-family:’Arimo’,system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
color:var(–inc-txt);
}
.rs-inc, .rs-inc *{ box-sizing:border-box; }
.rs-inc .wrap{
border-radius:var(–inc-radius);
background:var(–inc-bg);
border:0;
box-shadow:0 4px 16px rgba(11,18,32,.08), 0 1px 4px rgba(11,18,32,.06);
overflow:hidden;
padding:var(–inc-pad);
}
.rs-inc .titlebar{
display:flex;
align-items:flex-end;
justify-content:space-between;
gap:12px;
margin:0 0 12px 0;
padding:0 0 10px 0;
border-bottom:1px solid rgba(11,18,32,.10);
}
.rs-inc .title{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-size:18px;
font-weight:550;
color:var(–inc-txt) !important;
letter-spacing:.2px;
}
.rs-inc .badge{
margin:0 !important;
color:var(–inc-muted) !important;
font-weight:500;
font-size:12px;
letter-spacing:.2px;
white-space:nowrap;
}
.rs-inc .badge b{ color:var(–inc-accent); }
.rs-inc .card{
border:1px solid rgba(11,18,32,.14);
border-radius:12px;
background:#ffffff;
padding:12px;
min-width:0;
}
.rs-inc .rowhead{
display:flex;
align-items:center;
gap:10px;
margin:0 0 10px 0;
}
.rs-inc .label{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-weight:600;
letter-spacing:.2px;
text-transform:uppercase;
font-size:12px;
color:rgba(11,18,32,.70) !important;
}
.rs-inc .bul{
width:100%;
border-collapse:collapse !important;
border-spacing:0 !important;
border:0 !important;
margin:0;
box-shadow:none !important;
background-image:none !important;
outline:0 !important;
}
.rs-inc .bul tbody,
.rs-inc .bul tr,
.rs-inc .bul td{
border:0 !important;
box-shadow:none !important;
background-image:none !important;
outline:0 !important;
}
.rs-inc .bul td{
padding:0;
vertical-align:top;
}
.rs-inc .bul .b{
width:var(–inc-indent);
padding-right:10px;
color:rgba(11,18,32,.35);
font-size:14px;
line-height:1.5;
}
.rs-inc .bul .t{
font-size:14px;
font-weight:500;
line-height:1.5;
color:var(–inc-txt);
padding-bottom:6px;
}
.rs-inc .bul tr:last-child .t{ padding-bottom:0; }
.rs-inc .note{
margin:10px 0 0 0;
color:var(–inc-muted);
font-size:12px;
line-height:1.35;
}
@media (max-width: 640px){
.rs-inc .wrap{ padding:14px; }
}
| • | Explorer Vision Bionic Quadruped Robot |
| • | Default Leg Modules (4 pc) |
| • | Bluetooth Remote Controller |
| • | Charging Dock |
| • | High-Capacity Battery Pack |
| • | Intel RealSense D435i |
| • | Enhanced Camera SDK |
Package contents vary by configuration.
padding-top:18px;
–dims-bg:#f8f8f8;
–dims-line:rgba(11,18,32,.14);
–dims-txt:#0b1220;
–dims-muted:rgba(11,18,32,.70);
–dims-accent:#00446a;
–dims-radius:15px;
–dims-pad:16px;
–dims-indent:18px;
font-family:’Arimo’,system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
color:var(–dims-txt);
}
.rs-dims, .rs-dims *{ box-sizing:border-box; }
.rs-dims .wrap{
border-radius:var(–dims-radius);
background:var(–dims-bg);
border:0;
box-shadow:0 4px 16px rgba(11,18,32,.08), 0 1px 4px rgba(11,18,32,.06);
overflow:hidden;
padding:var(–dims-pad);
}
.rs-dims .titlebar{
display:flex;
align-items:flex-end;
justify-content:space-between;
gap:12px;
margin:0 0 12px 0;
padding:0 0 10px 0;
border-bottom:1px solid rgba(11,18,32,.10);
}
.rs-dims .title{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-size:18px;
font-weight:550;
color:var(–dims-txt) !important;
letter-spacing:.2px;
}
.rs-dims .badge{
margin:0 !important;
color:var(–dims-muted) !important;
font-weight:500;
font-size:12px;
letter-spacing:.2px;
white-space:nowrap;
}
.rs-dims .badge b{ color:var(–dims-accent); }
.rs-dims .hi{
display:grid;
grid-template-columns:repeat(12,minmax(0,1fr));
gap:10px;
}
.rs-dims .tile{
grid-column:span 6;
border:1px solid rgba(11,18,32,.14);
border-radius:12px;
background:#ffffff;
padding:12px;
min-width:0;
}
.rs-dims .tile b{
display:block;
font-family:’Poppins’,sans-serif;
font-size:12px;
letter-spacing:.2px;
color:rgba(11,18,32,.65);
margin-bottom:8px;
line-height:1.15;
font-weight:600;
text-transform:uppercase;
}
.rs-dims .bul{
width:100%;
border-collapse:collapse !important;
border-spacing:0 !important;
border:0 !important;
margin:0;
box-shadow:none !important;
background-image:none !important;
outline:0 !important;
}
.rs-dims .bul tbody,
.rs-dims .bul tr,
.rs-dims .bul td{
border:0 !important;
box-shadow:none !important;
background-image:none !important;
outline:0 !important;
}
.rs-dims .bul td{
padding:0;
vertical-align:top;
}
.rs-dims .bul .b{
width:var(–dims-indent);
padding-right:10px;
color:rgba(11,18,32,.35);
font-size:14px;
line-height:1.5;
}
.rs-dims .bul .t{
font-size:14px;
font-weight:500;
line-height:1.5;
color:var(–dims-txt);
}
.rs-dims .note{
margin:10px 0 0 0;
color:var(–dims-muted);
font-size:12px;
line-height:1.35;
}
@media (max-width: 640px){
.rs-dims .wrap{ padding:14px; }
.rs-dims .tile{ grid-column:1 / -1; }
}
| • | 18.5 kg |
| • | 761 x 372 x 428 mm |
Values shown are from the manufacturer’s reference.
padding-top:18px;
–links-bg:#f8f8f8;
–links-txt:#0b1220;
–links-muted:rgba(11,18,32,.70);
–links-accent:#00446a;
–links-radius:15px;
–links-pad:16px;
–links-indent:18px;
–links-gap:10px;
font-family:’Arimo’,system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
color:var(–links-txt);
}
.rs-links, .rs-links *{ box-sizing:border-box; }
.rs-links hr{ display:none !important; }
.rs-links .rsln-wrap{
border-radius:var(–links-radius);
background:var(–links-bg);
border:0;
box-shadow:0 4px 16px rgba(11,18,32,.08), 0 1px 4px rgba(11,18,32,.06);
overflow:hidden;
padding:var(–links-pad);
}
.rs-links .rsln-titlebar{
display:flex;
align-items:flex-end;
justify-content:space-between;
gap:12px;
margin:0 0 12px 0;
padding:0 0 10px 0;
border-bottom:1px solid rgba(11,18,32,.10);
}
.rs-links .rsln-title{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-size:18px;
font-weight:550;
color:var(–links-txt) !important;
letter-spacing:.2px;
}
.rs-links .rsln-badge{
margin:0 !important;
color:var(–links-muted) !important;
font-weight:500;
font-size:12px;
letter-spacing:.2px;
white-space:nowrap;
}
.rs-links .rsln-badge b{ color:var(–links-accent); }
.rs-links .rsln-grid{
display:grid;
grid-template-columns:repeat(12,minmax(0,1fr));
gap:10px;
}
.rs-links .rsln-card{
grid-column:span 12;
border:1px solid rgba(11,18,32,.14);
border-radius:12px;
background:#ffffff;
padding:12px;
min-width:0;
}
.rs-links .rsln-head{
margin:0 0 10px 0 !important;
font-family:’Poppins’,sans-serif;
font-weight:600;
letter-spacing:.2px;
text-transform:uppercase;
font-size:12px;
color:rgba(11,18,32,.70) !important;
}
.rs-links .rsln-item{
display:flex;
align-items:flex-start;
gap:var(–links-gap);
margin:6px 0;
padding:0;
}
.rs-links .rsln-item:first-child{ margin-top:0; }
.rs-links .rsln-item:last-child{ margin-bottom:0; }
.rs-links .rsln-bullet{
width:var(–links-indent);
flex:0 0 var(–links-indent);
color:rgba(11,18,32,.35);
font-size:14px;
line-height:1.5;
}
.rs-links .rsln-text{
min-width:0;
font-size:14px;
font-weight:500;
line-height:1.5;
color:var(–links-txt) !important;
overflow-wrap:anywhere;
}
.rs-links .rsln-text a,
.rs-links .rsln-text a:link,
.rs-links .rsln-text a:visited{
display:inline !important;
font-size:inherit !important;
line-height:inherit !important;
font-weight:500 !important;
color:var(–links-txt) !important;
text-decoration:none !important;
text-indent:0 !important;
letter-spacing:normal !important;
white-space:normal !important;
background:none !important;
border:0 !important;
padding:0 !important;
margin:0 !important;
opacity:1 !important;
visibility:visible !important;
overflow:visible !important;
}
.rs-links .rsln-text a:before,
.rs-links .rsln-text a:after{
content:none !important;
}
.rs-links .rsln-text a:hover{
text-decoration:underline !important;
text-underline-offset:2px;
}
.rs-links .rsln-grid,
.rs-links .rsln-card{
background-image:none !important;
box-shadow:none !important;
outline:0 !important;
}
@media (max-width: 640px){
.rs-links .rsln-wrap{ padding:14px; }
}
padding-top:18px;
–cmp-bg:#f8f8f8;
–cmp-line:rgba(11,18,32,.14);
–cmp-txt:#0b1220;
–cmp-muted:rgba(11,18,32,.70);
–cmp-accent:#00446a;
–cmp-radius:15px;
–cmp-pad:16px;
–cmp-indent:18px;
font-family:’Arimo’,system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
color:var(–cmp-txt);
}
.rs-cmp, .rs-cmp *{ box-sizing:border-box; }
.rs-cmp .wrap{
border-radius:var(–cmp-radius);
background:var(–cmp-bg);
border:0; box-shadow:0 4px 16px rgba(11,18,32,.08), 0 1px 4px rgba(11,18,32,.06); overflow:hidden;
padding:var(–cmp-pad);
}
.rs-cmp .titlebar{
display:flex; align-items:flex-end; justify-content:space-between;
gap:12px; margin:0 0 12px 0; padding:0 0 10px 0;
border-bottom:1px solid rgba(11,18,32,.10);
}
.rs-cmp .title{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-size:18px; font-weight:550;
color:var(–cmp-txt) !important;
letter-spacing:.2px;
}
.rs-cmp .badge{
margin:0 !important;
color:var(–cmp-muted) !important;
font-weight:500; font-size:12px; letter-spacing:.2px; white-space:nowrap;
}
.rs-cmp .badge b{ color:var(–cmp-accent); }
.rs-cmp .sectionlabel{
margin:12px 0 6px 0;
font-family:’Poppins’,sans-serif;
font-size:12px; color:var(–cmp-muted);
letter-spacing:.25px; font-weight:600; text-transform:uppercase;
}
.rs-cmp .hi{
display:grid; grid-template-columns:repeat(12,minmax(0,1fr));
gap:10px; margin:10px 0 10px 0;
}
.rs-cmp .tile{
grid-column:span 3;
border:1px solid rgba(11,18,32,.14);
border-radius:12px; background:#ffffff;
padding:12px; min-width:0;
}
.rs-cmp .tile b{
display:block;
font-family:’Poppins’,sans-serif;
font-size:12px; letter-spacing:.2px;
color:rgba(11,18,32,.65); margin:0 0 8px 0;
line-height:1.15; font-weight:600; text-transform:uppercase;
}
.rs-cmp .bul{
width:100%; border-collapse:collapse !important;
border-spacing:0 !important; border:0 !important; margin:0;
box-shadow:none !important; background-image:none !important; outline:0 !important;
}
.rs-cmp .bul tbody,
.rs-cmp .bul tr,
.rs-cmp .bul td{
border:0 !important; box-shadow:none !important;
background-image:none !important; outline:0 !important;
}
.rs-cmp .bul td{ padding:0; vertical-align:top; }
.rs-cmp .bul .b{
width:var(–cmp-indent); padding-right:10px;
color:rgba(11,18,32,.35); font-size:14px; line-height:1.5;
}
.rs-cmp .bul .t{
font-size:14px; font-weight:500; line-height:1.5;
color:var(–cmp-txt); overflow-wrap:anywhere;
}
.rs-cmp table.cmp-table,
.rs-cmp table.cmp-table thead,
.rs-cmp table.cmp-table tbody,
.rs-cmp table.cmp-table tfoot,
.rs-cmp table.cmp-table tr,
.rs-cmp table.cmp-table th,
.rs-cmp table.cmp-table td{
border:0 !important;
border-collapse:collapse !important;
box-shadow:none !important;
outline:0 !important;
background:transparent !important;
background-color:transparent !important;
background-image:none !important;
}
.rs-cmp table.cmp-table{
width:100%; margin-top:10px;
border-top:1px solid rgba(11,18,32,.10) !important;
}
.rs-cmp table.cmp-table tr{ border-bottom:1px solid rgba(11,18,32,.08) !important; }
.rs-cmp table.cmp-table tr:last-child{ border-bottom:none !important; }
.rs-cmp table.cmp-table td{
padding:10px 0; vertical-align:top; font-size:14px;
}
.rs-cmp table.cmp-table td:not(:last-child){ padding-right:14px; }
.rs-cmp .cmp-k{ color:var(–cmp-muted); font-weight:500; width:32%; }
.rs-cmp .cmp-v{ color:var(–cmp-txt); font-weight:500; overflow-wrap:anywhere; }
.rs-cmp .cmp-muted{ color:var(–cmp-muted); font-weight:500; }
.rs-cmp .cmp-head td{
font-family:’Poppins’,sans-serif;
font-size:12px; font-weight:600;
color:rgba(11,18,32,.65); text-transform:uppercase; letter-spacing:.2px;
padding-bottom:8px; border-bottom:2px solid rgba(11,18,32,.14) !important;
}
.rs-cmp .cmp-head td:first-child{ color:transparent; }
.rs-cmp .cmp-head td.cmp-active{
color:var(–cmp-accent);
border-bottom-color:var(–cmp-accent) !important;
}
.rs-cmp .cmp-v.cmp-active{
color:var(–cmp-txt);
font-weight:550;
}
.rs-cmp .cmp-head td.cmp-inactive{
color:rgba(11,18,32,.40);
}
.rs-cmp .cmp-v.cmp-inactive{
color:rgba(11,18,32,.50);
font-weight:500;
}
@media (max-width: 980px){
.rs-cmp .tile{ grid-column:span 6; }
}
@media (max-width: 640px){
.rs-cmp .wrap{ padding:14px; }
.rs-cmp .tile{ grid-column:1 / -1; }
.rs-cmp table.cmp-table,
.rs-cmp table.cmp-table thead,
.rs-cmp table.cmp-table tbody,
.rs-cmp table.cmp-table tr,
.rs-cmp table.cmp-table td{ display:block; width:100%; }
.rs-cmp .cmp-head{ display:none; }
.rs-cmp table.cmp-table tr{ padding:10px 0; }
.rs-cmp table.cmp-table td{ padding:0; padding-right:0 !important; }
.rs-cmp .cmp-k{
width:100%;
padding-top:0;
padding-bottom:4px;
font-size:14px;
border-bottom:1px solid rgba(11,18,32,.08);
margin-bottom:4px;
}
.rs-cmp .cmp-v{
display:block;
padding:6px 0 2px 0;
font-size:14px;
}
.rs-cmp .cmp-v::before{
content: attr(data-model);
display:block;
font-family:’Poppins’,sans-serif;
font-size:11px;
font-weight:600;
text-transform:uppercase;
letter-spacing:.3px;
color:rgba(11,18,32,.35);
margin-bottom:2px;
}
.rs-cmp .cmp-v.cmp-active::before{
color:var(–cmp-accent);
}
.rs-cmp .cmp-v.cmp-inactive{
color:rgba(11,18,32,.45);
}
}
| • | 8000 mAh extended battery, approx. 2.5 hrs runtime |
| • | 40 TOPS onboard compute (Orin Nano) |
| • | Dual built-in + Intel RealSense D435i |
| • | Enhanced Camera SDK included |
| Explorer | Explorer Vision | Explorer Sentinel | |
| Product Type | Bio-Inspired Quadruped Robot | Bio-Inspired Quadruped Robot | Bio-Inspired Quadruped Robot |
| Battery Capacity | 4000 mAh | 8000 mAh | 8000 mAh |
| Battery Configuration | Standard | Extended | Extended |
| Operating Time | Approx. 1.5 hrs | Approx. 2.5 hrs | Approx. 2.5 hrs |
| Max Speed (Legged) | 1.8 m/s | 1.8 m/s | 1.8 m/s |
| Max Speed (Wheeled) | 3.0 m/s | 3.0 m/s | 3.0 m/s |
| Climbing Ability | 30 to 35-degree slopes | 30 to 35-degree slopes | 30 to 35-degree slopes |
| Obstacle Clearance | Up to 16 cm | Up to 16 cm | Up to 16 cm |
| Effective Payload | 3 to 7 kg | 3 to 7 kg | 3 to 7 kg |
| Weight | 15.5 kg | 18.5 kg | 18.5 kg |
| AI Computing Module | Not included | 40 TOPS (Orin Nano) | 40 TOPS (Orin Nano) |
| RGB Cameras | Front and rear 1080P | Front and rear 1080P | Front and rear 1080P |
| Depth Camera | Dual built-in depth cameras | Dual built-in + Intel RealSense D435i | Dual built-in + Intel RealSense D435i |
| LiDAR | Not included | Not included | Yes |
| SLAM Navigation | Not included | Not included | Yes |
| Camera SDK | Not included | Enhanced Camera SDK | Enhanced Camera + LiDAR SDK |
| AI Voice Interaction | Yes | Dual-language | Dual-language |
| Autonomous Following | Yes | Yes | Yes |
| Obstacle Avoidance | Yes (bidirectional, auto-braking) | Yes (bidirectional, auto-braking) | Yes (bidirectional, auto-braking) |
| App Control | Wi-Fi / 4G | Wi-Fi / 4G | Wi-Fi / 4G |
| OTA Updates | Supported | Supported | Supported |
| SDK Support | C++ / Python SDK | C++ / Python SDK | C++ / Python SDK |
| Simulation Environment | Isaac Gym | Isaac Gym | Isaac Gym |
| Secondary Development | Supported | Supported | Supported |


Reviews
There are no reviews yet.