

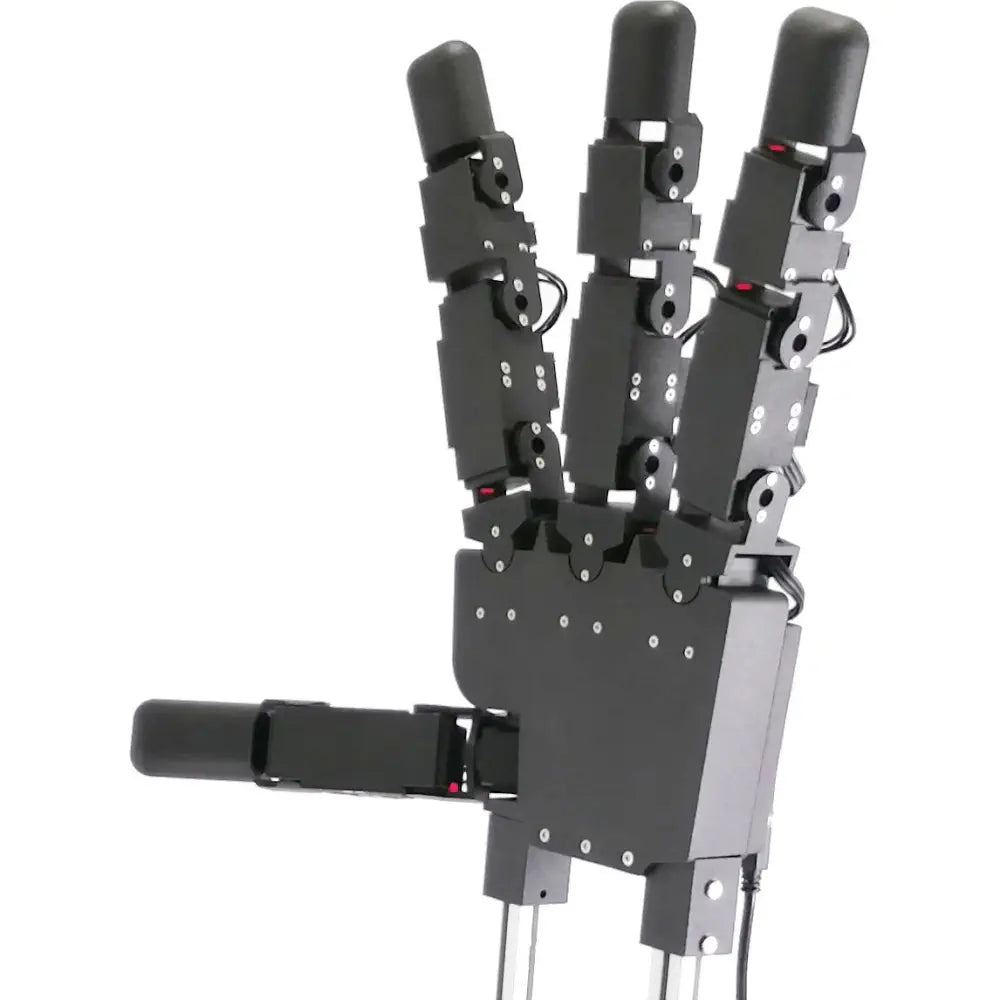
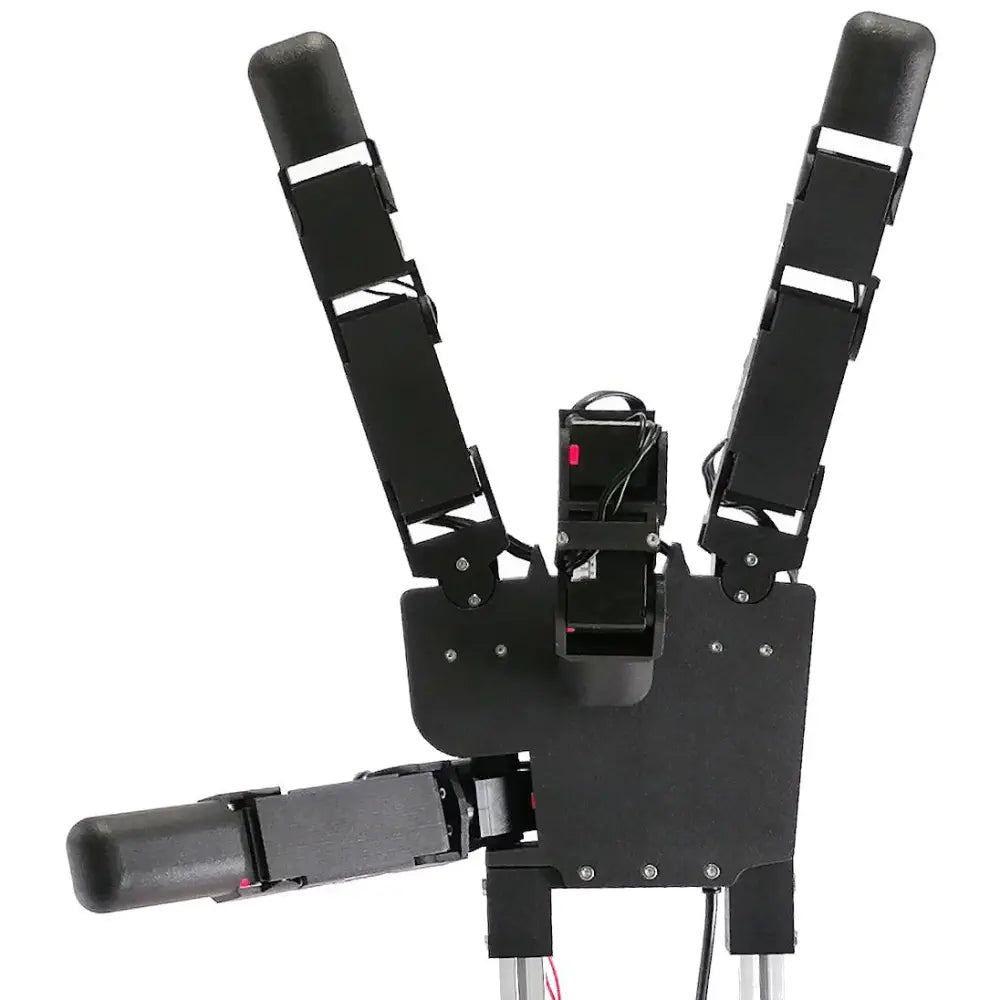
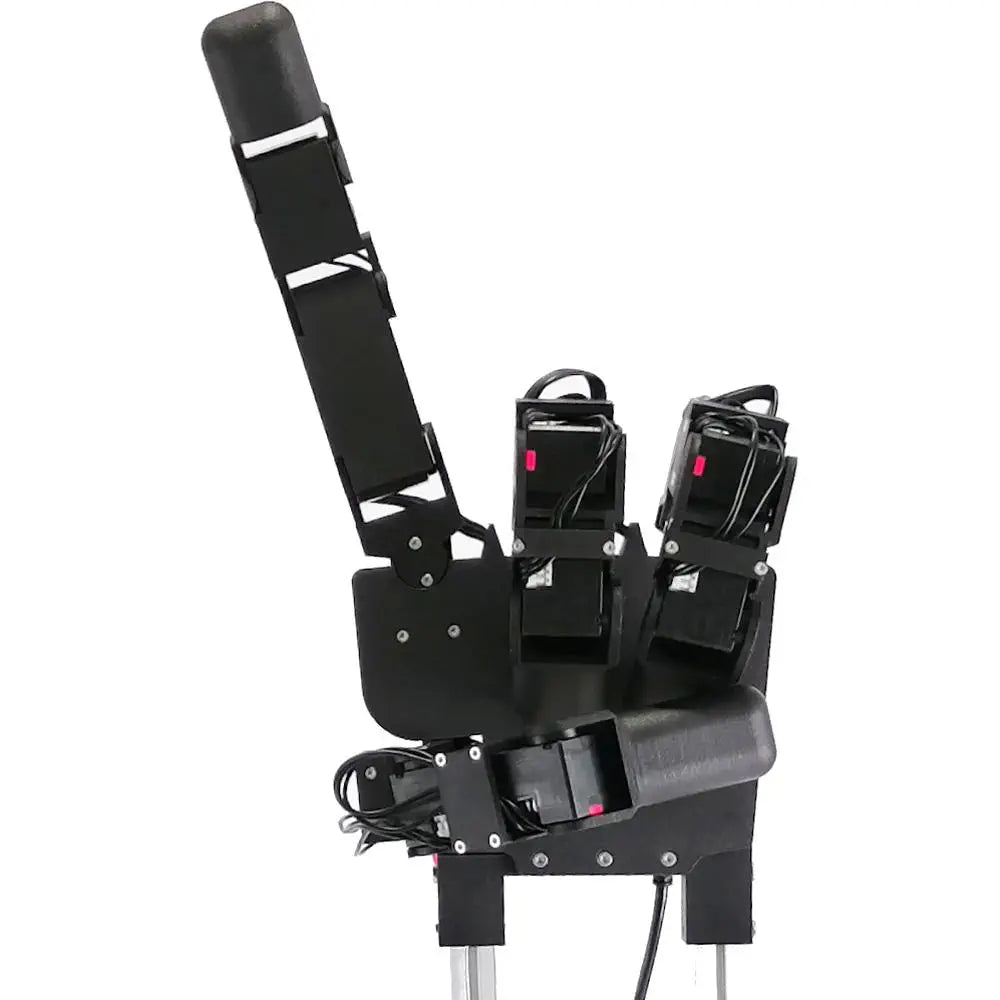
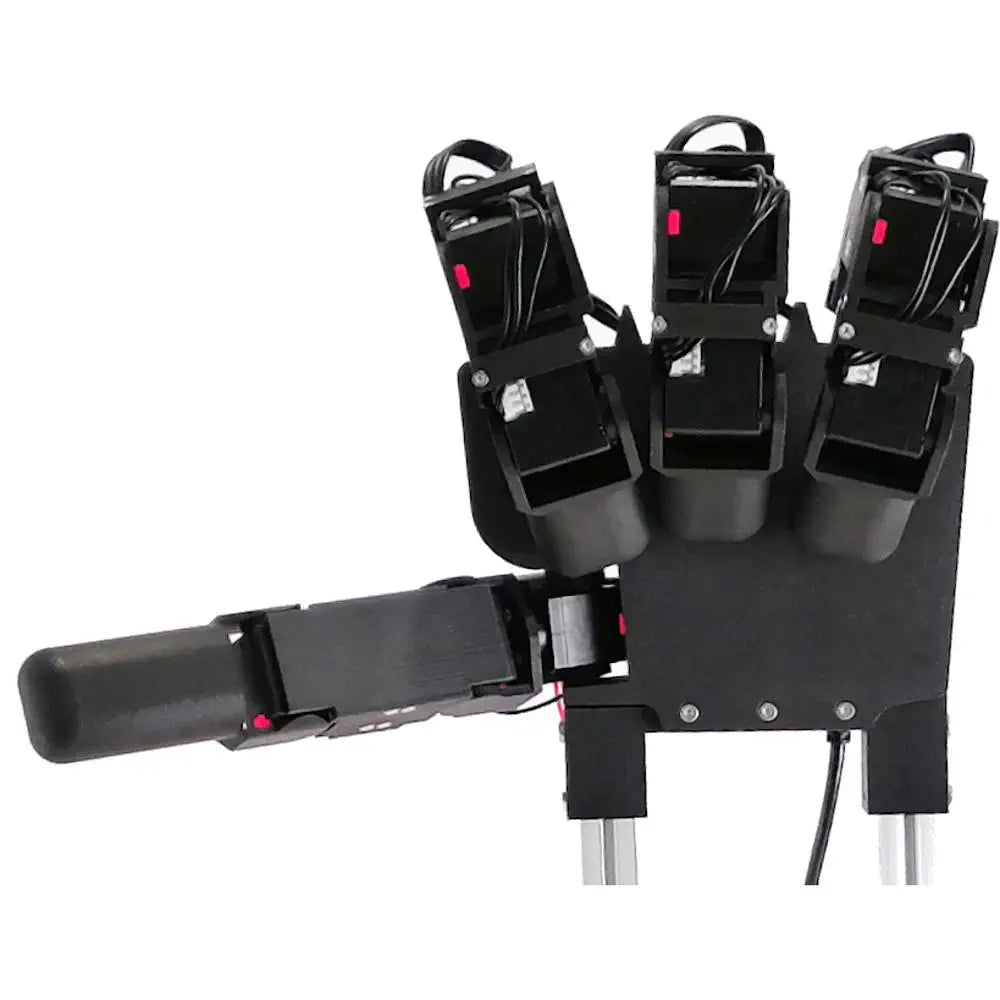
Description
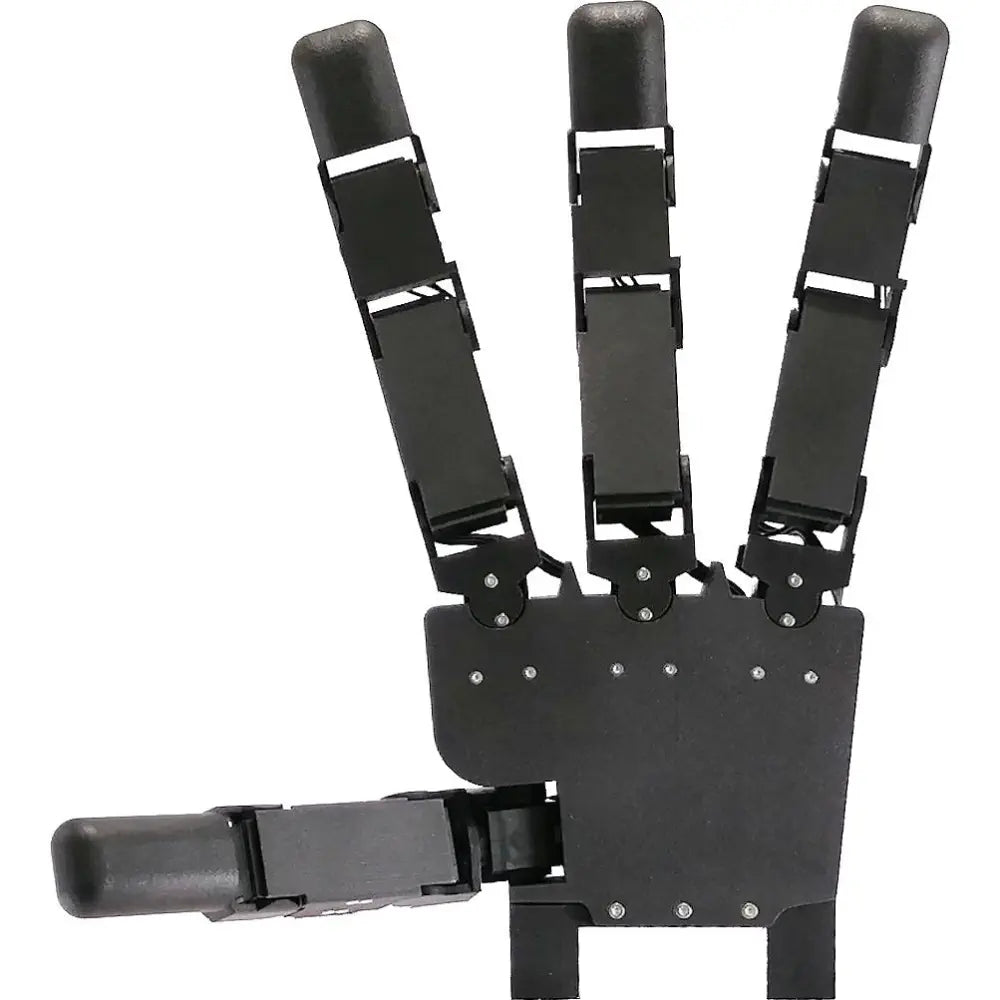
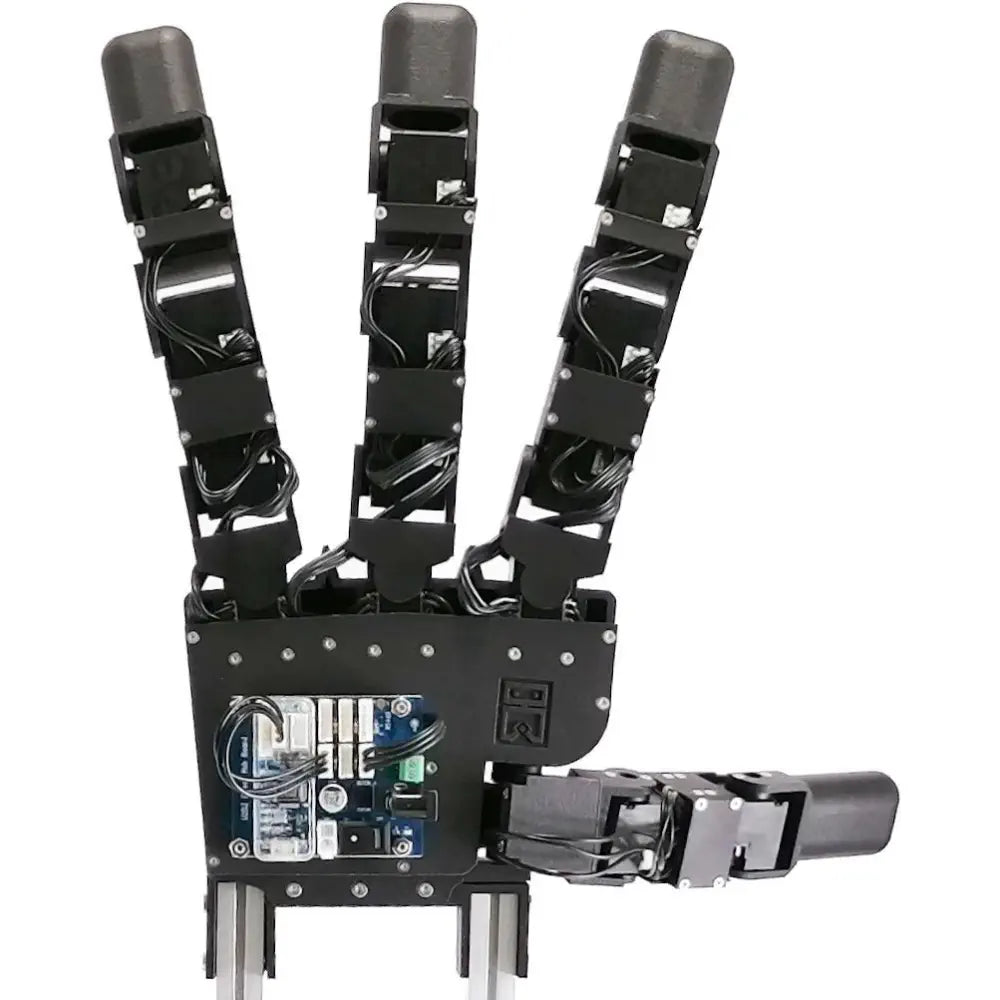
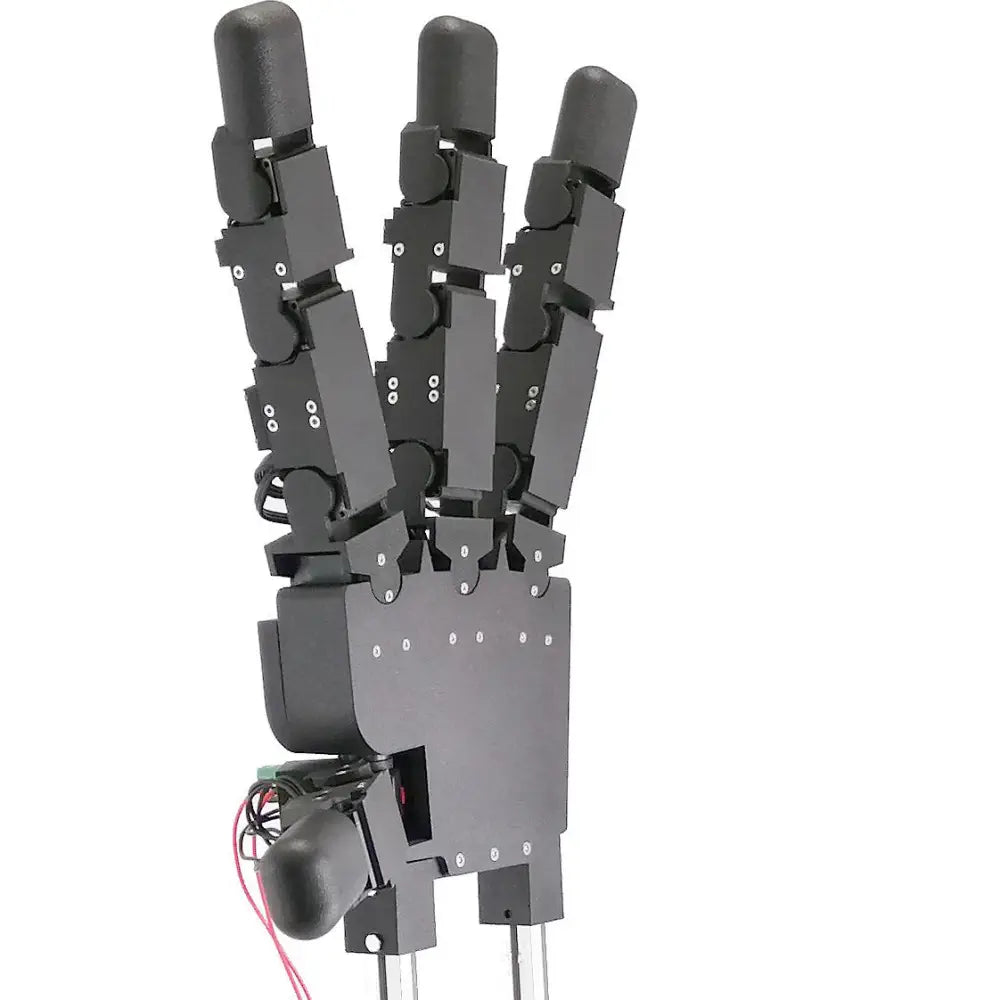
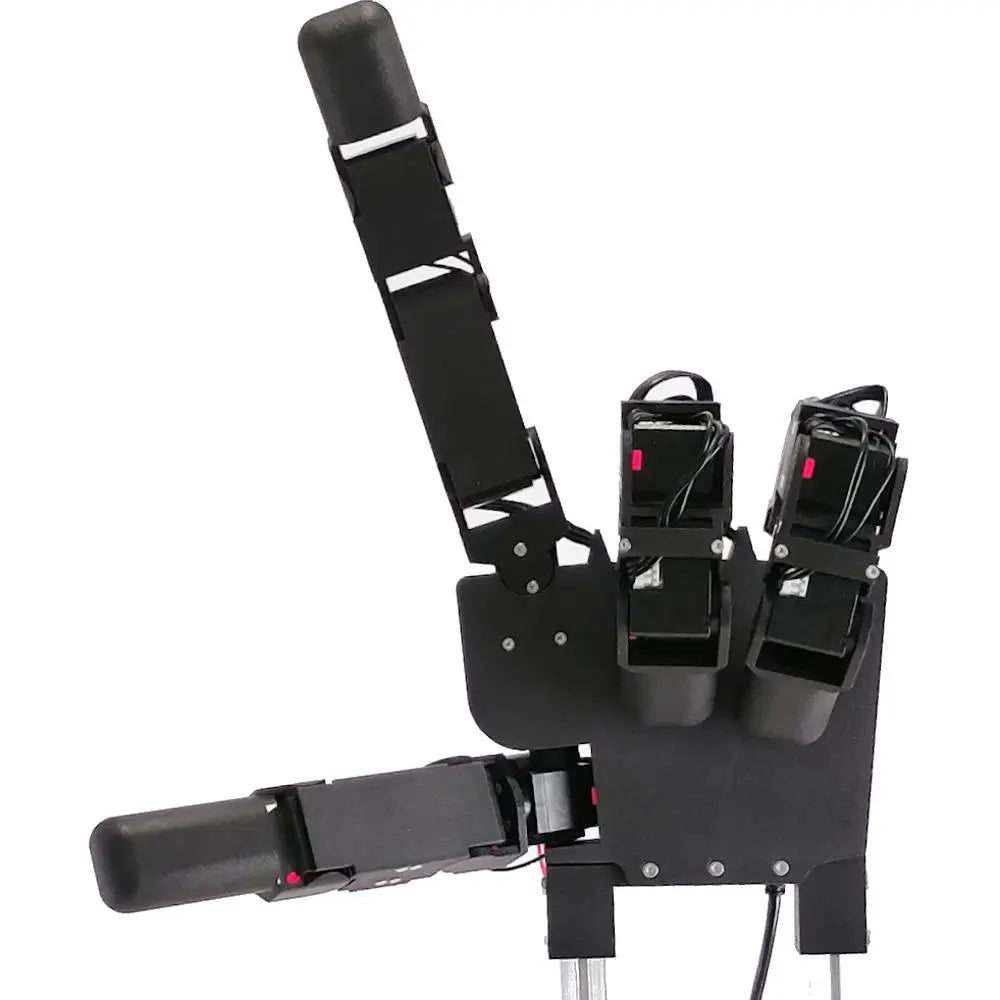
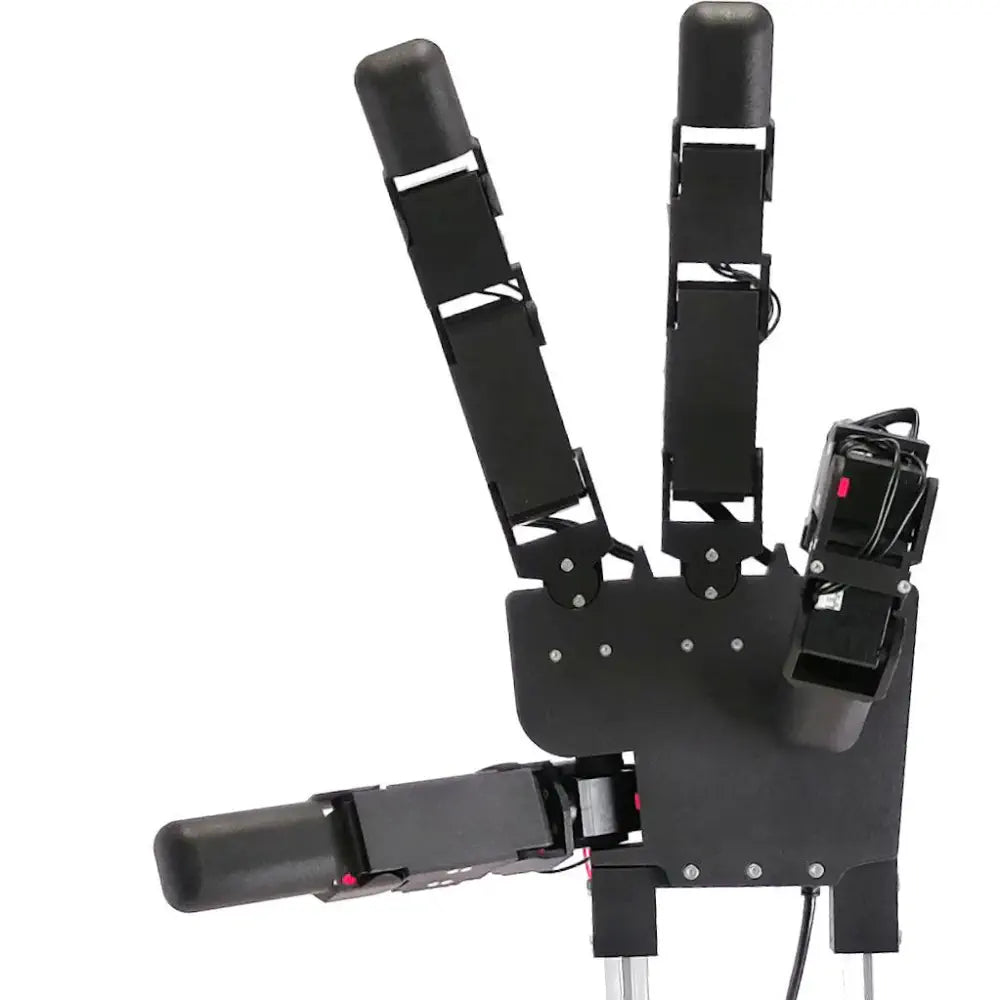
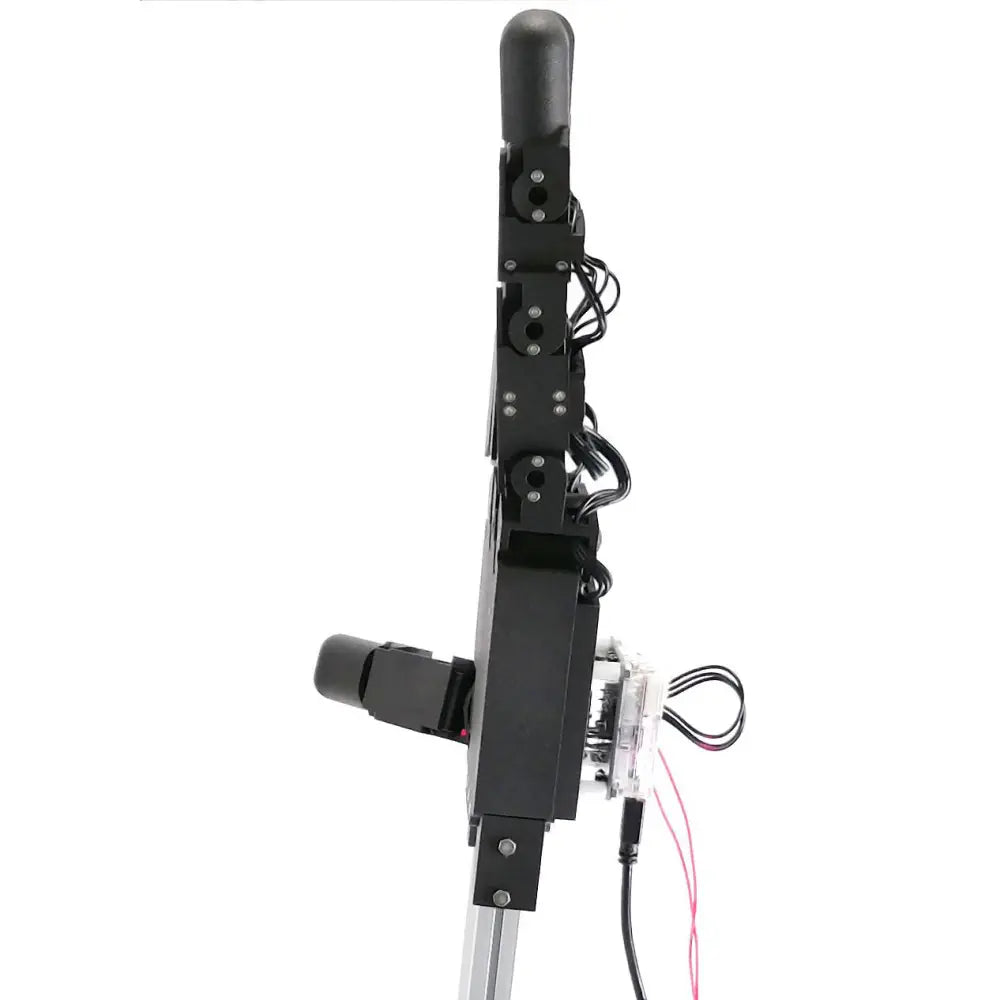
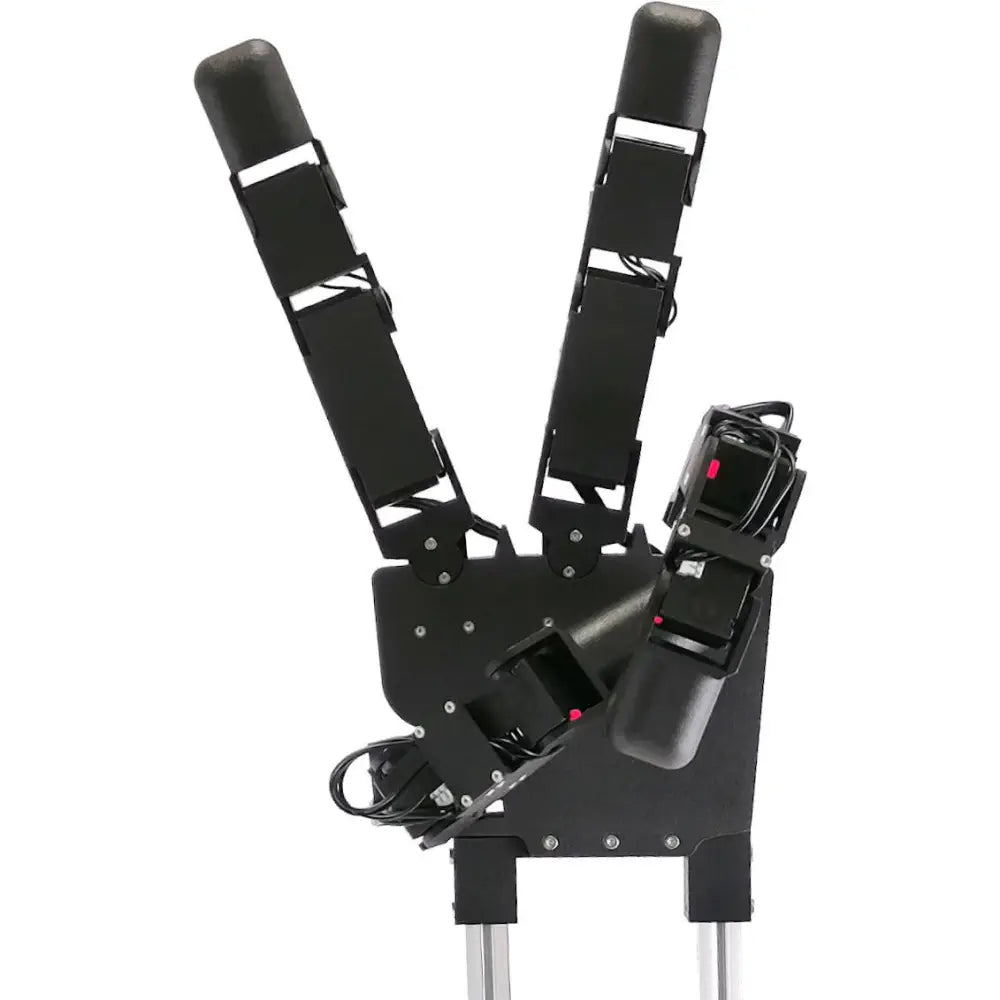
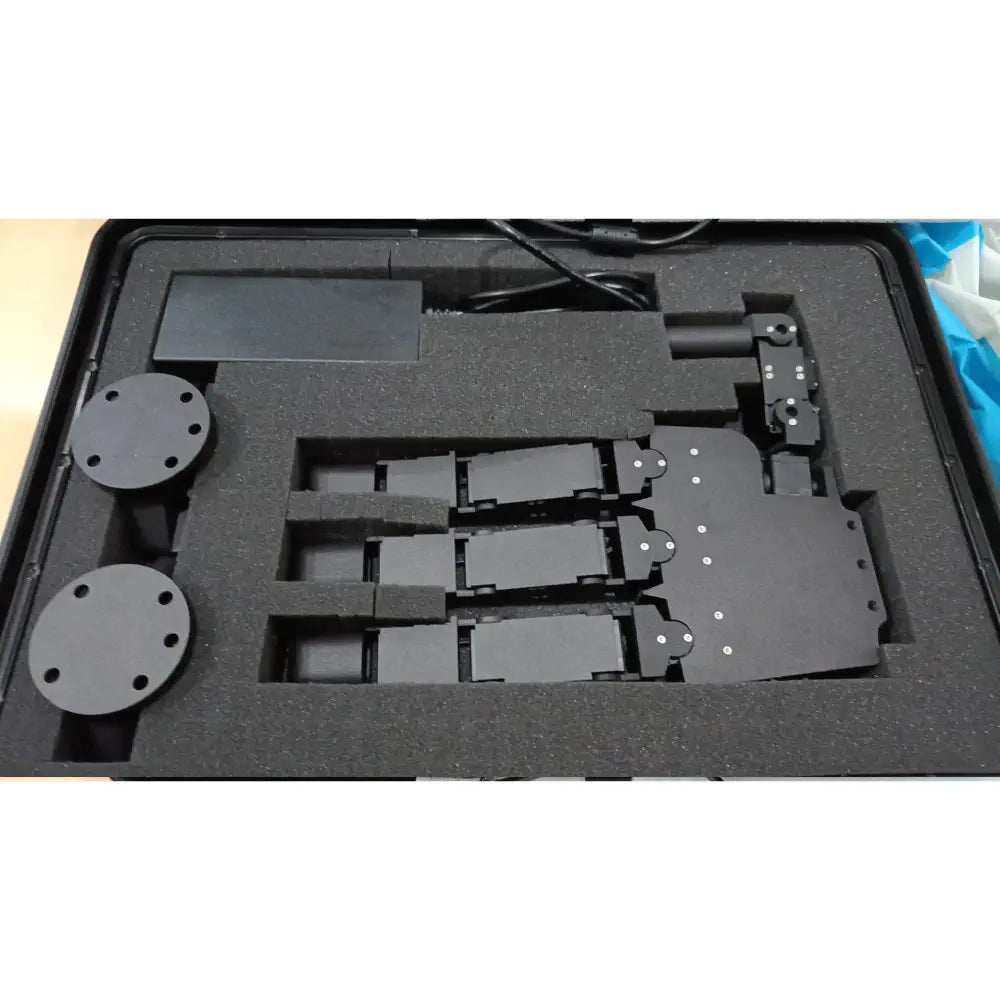
– Tilburg Hand (LEFT)
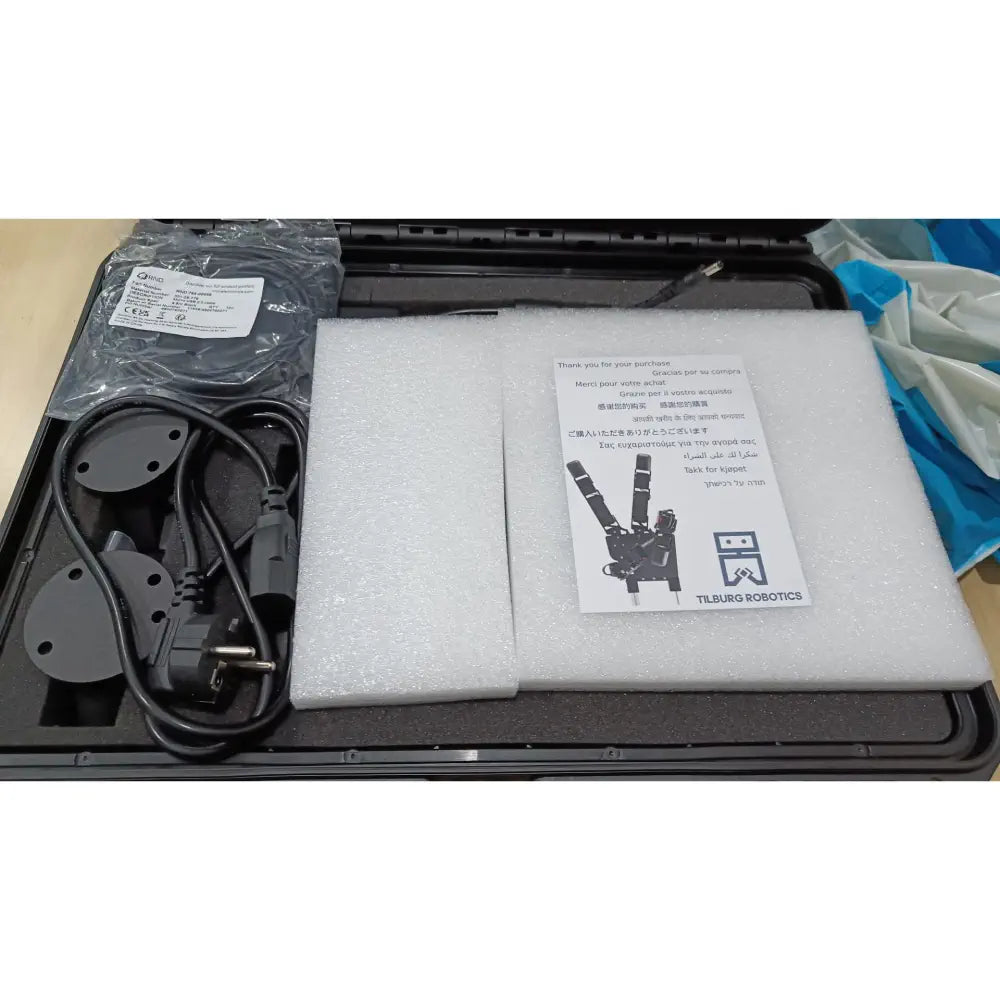
– Power supply and cables
– Long USB cable
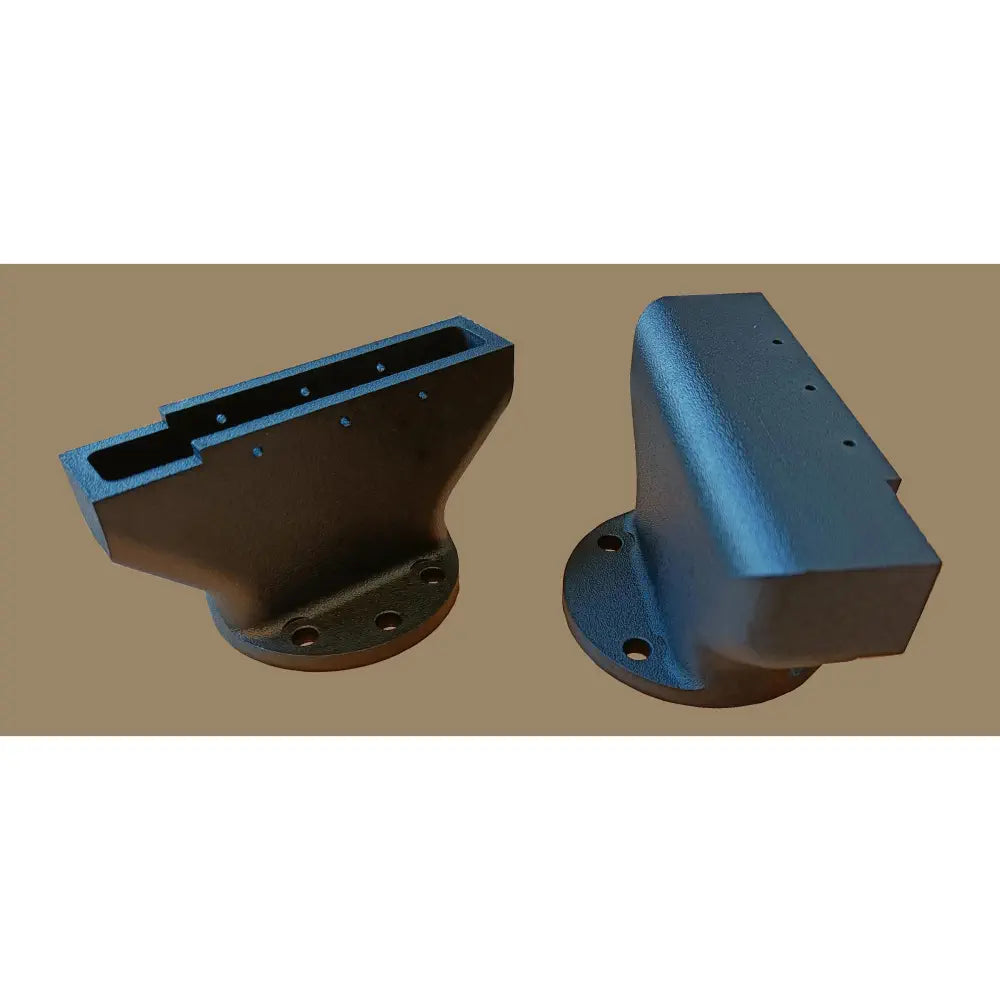
– Default wrist adapters compatible with UR robot flanges (4x M6 spaces 90 degrees apart on a 50mm radius)
** We are happy to provide customized adapters with your order. Please get in touch as soon as possible. Longer delivery times apply. **
– Sturdy carrying case with padding.
* Motors:
-16x Dynamixel XL330-M288 ( https://emanual.robotis.com/docs/en/dxl/x/xl330-m288 )
– Stall torque: 0.52 Nm (at 5V, 1.47A peak)
– No load speed: 103 rev/min (60 deg in 97ms)
– Feedback: position (12bit encoders), current-based torque sensing, velocity.
– Gear ratio: 288.4:1
– Configurable PID controller for each motor.
* Materials:
– High-quality industrial 3D printing is used to manufacture all plastic parts.
– Multi Jet Fusion 3D printed parts, PA12-HP Nylon.
* Software:
– Open source interface (Python).
– Easy to integrate with ROS; full integration planned for the future.
– Open source demos and examples.


Reviews
There are no reviews yet.