
Description
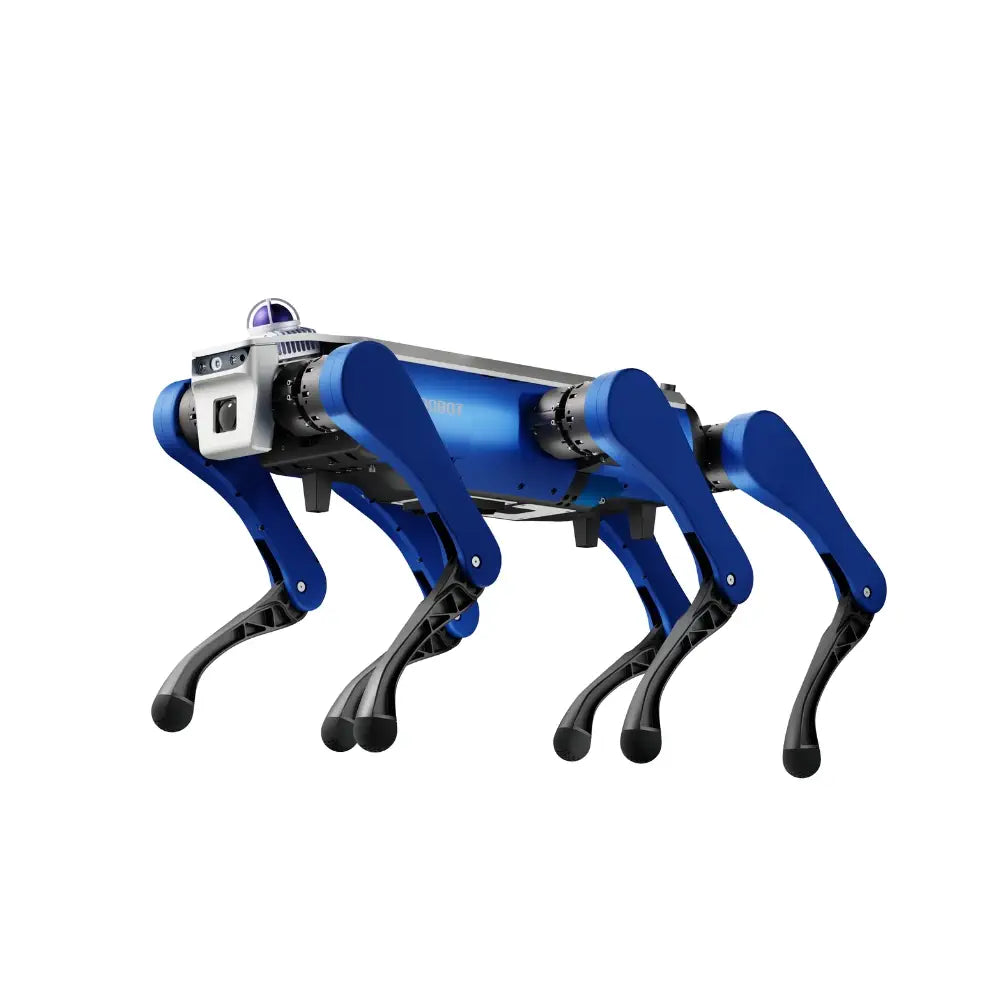
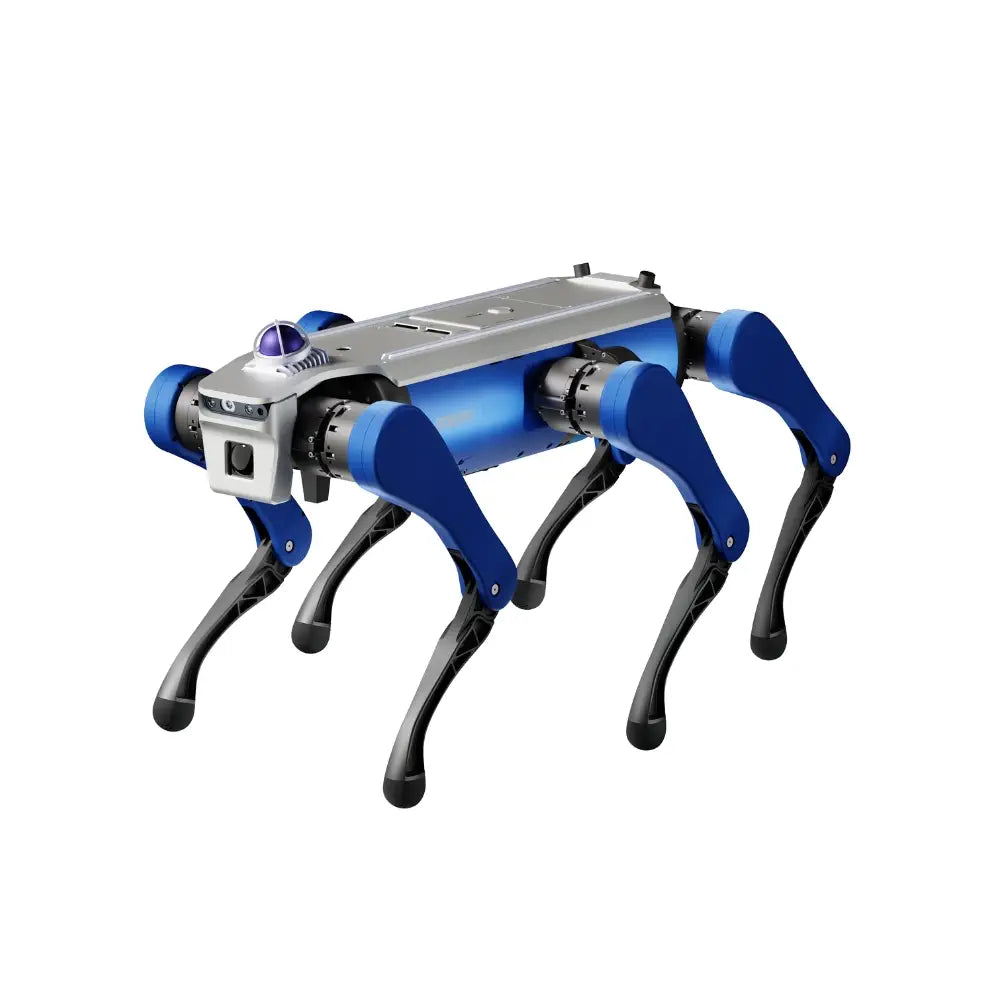
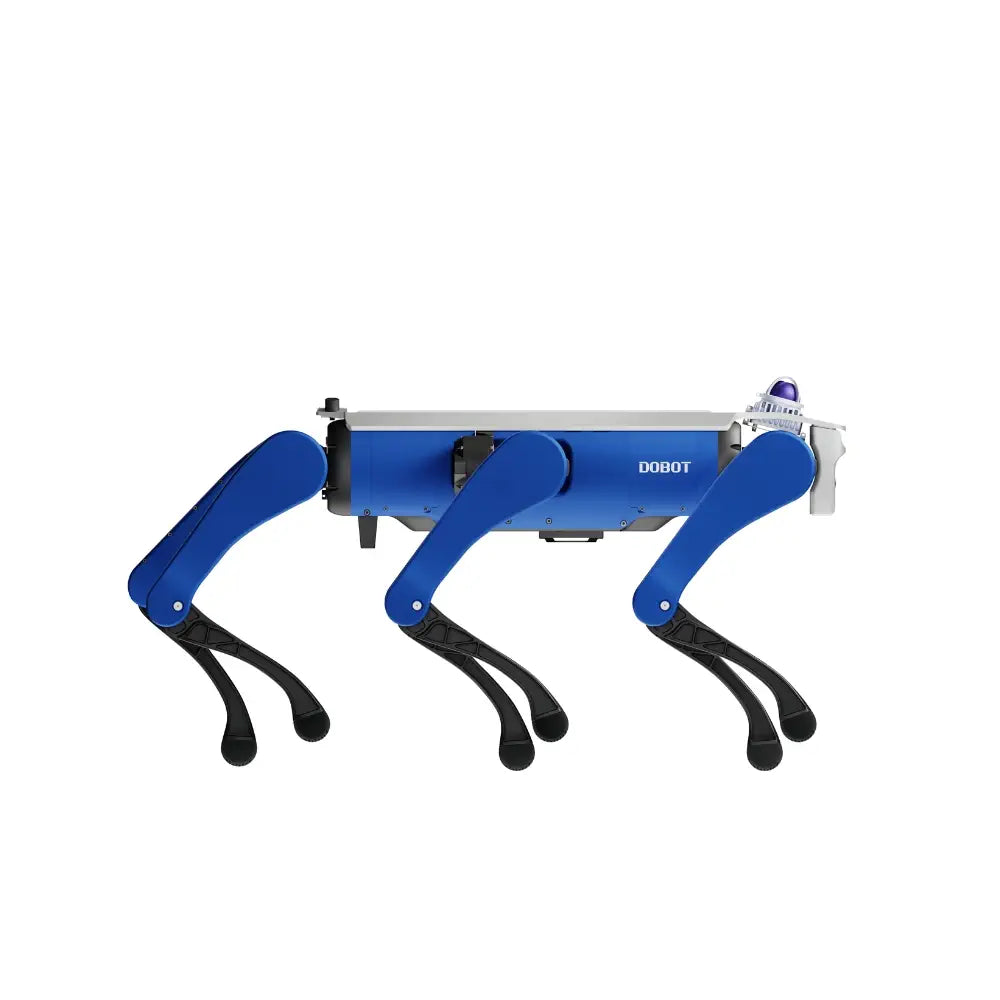
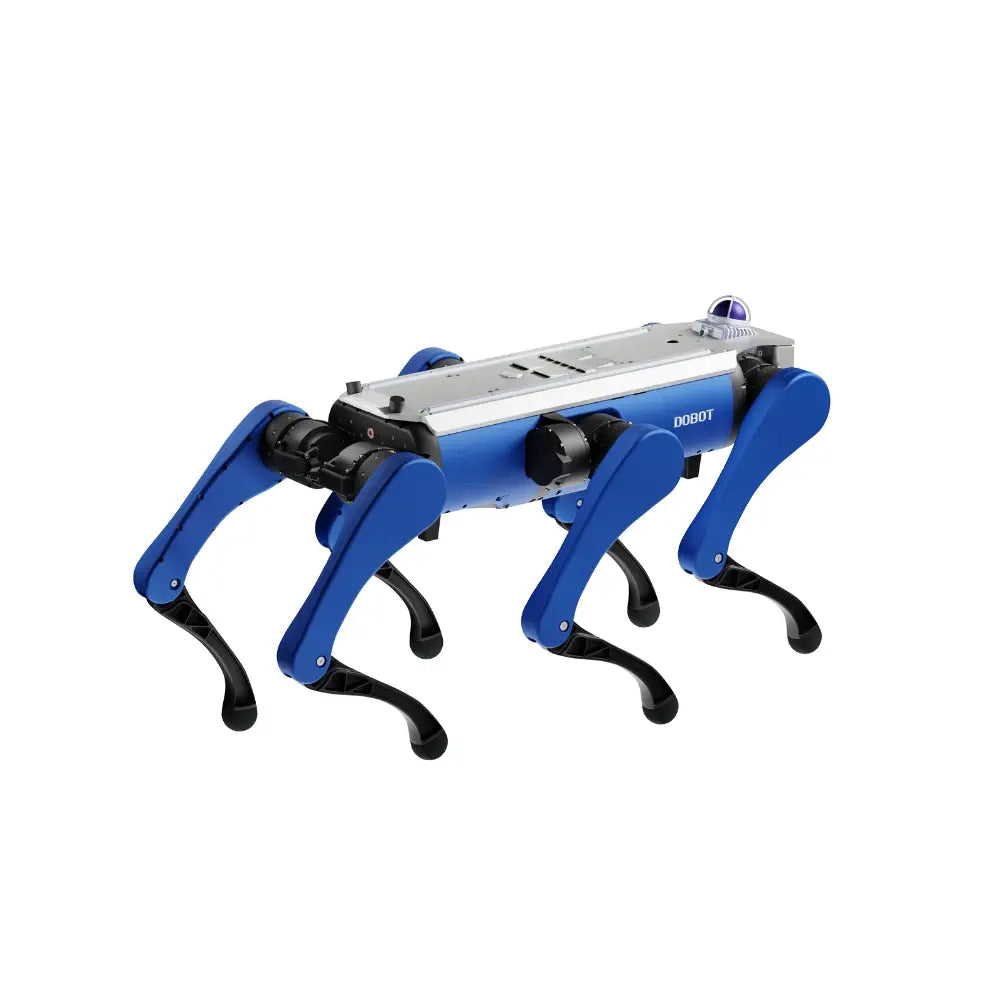
- Dobot Hexaplorer 6-legged Bionic Robot
- Agile 18-DOF hexapod platform with stable bionic tripod gait and self-recovery
- Fast & capable: up to 1.8 m/s speed and clears obstacles up to 20 cm
- Strong payload support: 10 kg rated capacity (15 kg max)
- Advanced dual compute: Intel Core i7/i5 Mini PC + Jetson Orin Nano (40 TOPS)
- Integrated perception: Livox Mid360 LiDAR and Intel RealSense D435 depth camera
- Developer-ready: ROS2 Humble with Python & C++ SDKs for high-level and joint control
- Long runtime: 504 Wh battery, up to 2.5 hours of operation, 1.5-hour charge time
Dobot Hexplorer 6-legged Bionic Robot is a professional hexapod locomotion platform developed by Shenzhen Dobot Corp Ltd, engineered for research, education, industrial inspection, and field deployment. Built around a biologically inspired six-legged architecture, it maintains a stable tripod gait that keeps three legs in contact with the ground at all times, combined with dynamic center-of-gravity control and anti-disturbance algorithms that enable autonomous self-recovery across uneven, slippery, and confined terrain. The platform supports slopes of up to 40 degrees, obstacles up to 20 cm in height, and achieves a maximum walking speed of 1.8 m/s, making it well-suited to complex real-world environments, including grassland, sand, gravel, wet surfaces, and stairs.
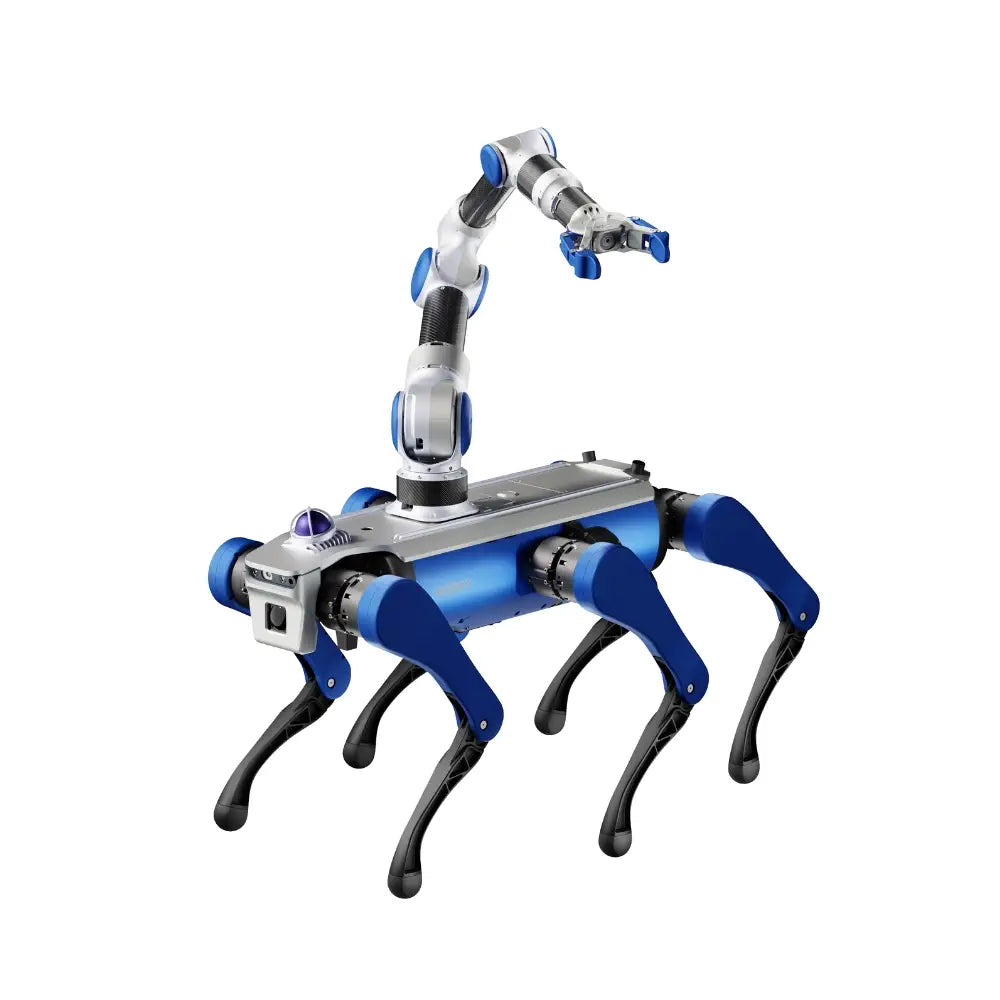
At the intelligence layer, Hexplorer integrates proprioceptive and exteroceptive sensing to enable real-time terrain awareness and adaptive gait adjustment without manual intervention. The onboard compute stack combines an x86 motion control PC with an ARM-based AI accelerator delivering 40 TOPS of GPU performance, supporting perception pipelines, autonomous navigation, obstacle avoidance, human detection, and target following. The platform ships with Ubuntu 22.04 and ROS2 Humble pre-configured, alongside a comprehensive SDK covering both high-level motion commands and low-level joint control in Python and C++, with simulation environments, debugging tools, and interface examples included. Its modular expansion rail supports future integration of collaborative robotic arms, remote video transmission, and wireless auto-charging, making it a flexible foundation for interdisciplinary robotics development across research institutions, universities, and commercial operators.
.rs-section.ai-food-Robqo{
background:var(–rsaf-bg,#fff);
border-radius:var(–rsaf-radius,12px);
padding:var(–rsaf-pad,18px);
color:var(–rsaf-tc,#222);
–rsaf-gap:2px;
}
/* heading gap (also affects “overall gap”) */
.rs-section.ai-food-Robqo .cc-heading{
margin:0 0 10px;
text-align:center;
font-weight:700;
font-size:clamp(16px, 1.6vw, 20px);
letter-spacing:.15px;
}
.rs-section.ai-food-Robqo .cc-grid{
display:grid;
grid-template-columns:repeat(4, minmax(0, 1fr));
gap:0;
align-items:stretch;
}
.rs-section.ai-food-Robqo .cc-col{
min-width:0;
padding:var(–rsaf-col-pad, 12px 16px);
text-align:left;
display:flex;
flex-direction:column;
justify-content:flex-start;
gap:var(–rsaf-gap,2px) !important;
}
/* separators */
.rs-section.ai-food-Robqo .cc-col + .cc-col{
border-left:1px solid var(–rsaf-sep,#e6e8ee);
}
/* FIX: make the title row NOT tall */
.rs-section.ai-food-Robqo .cc-row{
display:flex;
align-items:center;
justify-content:flex-start;
gap:10px;
/* key bits */
line-height:1 !important; /* prevents inherited tall line-height */
padding:0 !important;
margin:0 !important;
min-height:0 !important;
}
/* FIX: images can create extra baseline space; force block + no baseline */
.rs-section.ai-food-Robqo .cc-row img.cc-icon{
width:var(–rsaf-icon,28px);
height:var(–rsaf-icon,28px);
display:block !important;
line-height:0 !important;
vertical-align:middle !important;
margin:0 !important;
}
.rs-section.ai-food-Robqo .cc-title{
margin:0 !important;
padding:0 !important;
font-weight:700;
font-size:clamp(13px, 1.05vw, 15px);
line-height:1.05 !important; /* tighten */
}
.rs-section.ai-food-Robqo p.cc-desc{
margin:0 !important;
padding:0 !important;
margin-top:var(–rsaf-gap,2px) !important;
font-size:clamp(11.5px, .95vw, 12.5px);
line-height:1.3 !important;
color:var(–rsaf-muted,#6f7888);
max-width:36ch;
}
/* 2 cols on tablet */
@media (max-width:900px){
.rs-section.ai-food-Robqo .cc-grid{ grid-template-columns:repeat(2, minmax(0, 1fr)); }
.rs-section.ai-food-Robqo .cc-col + .cc-col{ border-left:0; }
.rs-section.ai-food-Robqo .cc-col{ border-top:1px solid var(–rsaf-sep,#e6e8ee); }
.rs-section.ai-food-Robqo .cc-col:nth-child(1),
.rs-section.ai-food-Robqo .cc-col:nth-child(2){ border-top:0; }
.rs-section.ai-food-Robqo .cc-col:nth-child(2),
.rs-section.ai-food-Robqo .cc-col:nth-child(4){
border-left:1px solid var(–rsaf-sep,#e6e8ee);
}
.rs-section.ai-food-Robqo p.cc-desc{ max-width:60ch; }
}
/* 1 col on mobile */
@media (max-width:650px){
.rs-section.ai-food-Robqo .cc-grid{ grid-template-columns:1fr; }
.rs-section.ai-food-Robqo .cc-col{
padding:12px 12px;
border-left:0 !important;
border-top:1px solid var(–rsaf-sep,#e6e8ee);
}
.rs-section.ai-food-Robqo .cc-col:first-child{ border-top:0; }
}

Genuine products with manufacturer-approved warranty coverage.

Customs, inspection, and prep handled locally before shipment.

Sales, support, and returns managed by one team.

Docs, tutorials, and community answers to move faster.
.rs-section.rs-stat-highlights img{display:block;vertical-align:top;max-width:100%;margin:0;padding:0;border:0}
.rs-section.rs-stat-highlights{background:transparent;padding:0px;border-radius:0px;font-family:’Arimo’,Arial,sans-serif}
.rs-section.rs-stat-highlights .rs-sh-grid{background:#f8f8f8;padding:28px 20px;border-radius:15px;display:flex;flex-wrap:wrap;justify-content:space-around;gap:24px;text-align:center;box-shadow:0 8px 24px -4px rgba(0,0,0,0.12)}
.rs-section.rs-stat-highlights .rs-sh-item{flex:1 1 18%;min-width:140px}
.rs-section.rs-stat-highlights .rs-sh-lbl{font-size:11px;font-weight:550;letter-spacing:.08em;text-transform:uppercase;color:#000000;line-height:1.4;margin:0 0 6px}
.rs-section.rs-stat-highlights .rs-sh-val{font-size:40px;font-weight:700;line-height:1.1;margin:0;letter-spacing:-.5px;color:#00456b;text-shadow:0 3px 8px rgba(0,0,0,0.18);font-family:’Poppins’,Arial,sans-serif}
@media(max-width:600px){.rs-section.rs-stat-highlights .rs-sh-item{flex:1 1 40%}}
rs-expand-panels — accordion hover panels
========================================================= */
.rs-ep-header{
text-align:center;
padding:0 0 22px 0;
max-width:740px;
margin:0 auto;
}
.rs-ep-header-title{
margin:0 0 14px 0 !important;
font-family:system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
font-size:clamp(22px,3vw,36px);
font-weight:800;
line-height:1.1;
color:#111;
}
.rs-ep-header-sub{
margin:0 !important;
font-family:system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
font-size:clamp(14px,1.6vw,17px);
line-height:1.55;
color:#444;
}
/* Flex container */
.rs-ep-wrap{
display:flex;
flex-wrap:nowrap;
gap:10px;
padding:0;
align-items:stretch;
width:100%;
height:400px;
box-sizing:border-box;
line-height:0;
}
/* Panel — mirrors rs-ip-panel exactly */
.rs-ep-panel{
position:relative;
min-width:0;
overflow:hidden;
border-radius:14px;
box-shadow:0 10px 26px rgba(0,0,0,.12);
height:100%;
display:block;
box-sizing:border-box;
isolation:isolate;
flex:1 1 0%;
margin:0 !important;
padding:0 !important;
border:0 !important;
outline:0 !important;
background:#222 !important;
font-family:system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
}
.rs-ep-panel, .rs-ep-panel *{
transition:none !important;
animation:none !important;
transform:none !important;
}
/* Image — direct child of panel, same as rs-ip-img */
.rs-ep-panel .rs-ep-img{
position:absolute;
inset:0 !important;
width:100% !important;
height:100% !important;
display:block !important;
margin:0 !important;
padding:0 !important;
border:0 !important;
object-fit:cover;
object-position:center 35%;
}
/* Closed overlay — ::after on panel, same as rs-ip-panel::after */
.rs-ep-panel::after{
content:””;
position:absolute;
inset:0;
z-index:1;
pointer-events:none;
background:linear-gradient(90deg, rgba(0,0,0,.72), rgba(0,0,0,.15));
opacity:1;
}
/* Collapsed label */
.rs-ep-panel .rs-ep-collapsed{
position:absolute;
top:12px;
left:12px;
right:40px;
z-index:2;
pointer-events:none;
margin:0 !important;
}
.rs-ep-panel .rs-ep-label{
display:block;
font-weight:800;
font-size:12px;
line-height:1.05;
letter-spacing:.15px;
color:#fff !important;
text-shadow:0 2px 14px rgba(0,0,0,.55);
pointer-events:auto;
}
.rs-ep-panel .rs-ep-arrow{
position:absolute;
top:0;
right:-28px;
font-size:18px;
line-height:1;
color:#fff;
opacity:.9;
pointer-events:none;
}
/* Expanded content — z-index:2, above ::after overlay */
.rs-ep-panel .rs-ep-expanded{
position:absolute;
inset:0;
z-index:2;
padding:22px 26px;
line-height:normal;
display:none;
color:#fff;
text-align:left;
pointer-events:none;
background:rgba(0,0,0,.50);
}
.rs-ep-panel .rs-ep-expanded b{ color:#fff; }
.rs-ep-panel .rs-ep-kv{ max-width:420px; }
/* Text nodes editable in WYSIWYG */
.rs-ep-panel .rs-ep-title,
.rs-ep-panel .rs-ep-chip,
.rs-ep-panel .rs-ep-row,
.rs-ep-panel .rs-ep-note{
pointer-events:auto;
}
.rs-ep-panel .rs-ep-title{
margin:0 0 14px 0 !important;
font-weight:900;
font-size:clamp(28px,3.0vw,44px);
letter-spacing:-0.3px;
line-height:1.02;
}
.rs-ep-panel .rs-ep-chip{
display:inline-block;
margin:2px 0 12px 0 !important;
padding:6px 10px;
border-radius:999px;
background:rgba(23,40,110,.92);
color:#fff;
font-size:12px;
font-weight:800;
}
.rs-ep-panel .rs-ep-row{
margin:8px 0 !important;
font-size:13px;
line-height:1.35;
}
.rs-ep-panel .rs-ep-note{
margin:6px 0 10px 0 !important;
font-size:12px;
color:rgba(255,255,255,.65);
}
/* —- DEFAULT OPEN STATE —- */
.rs-ep-panel.is-default{ flex:3 1 0%; }
.rs-ep-panel.is-default::after{ opacity:0; background:none; }
.rs-ep-panel.is-default .rs-ep-expanded{ display:block; }
.rs-ep-panel.is-default .rs-ep-collapsed{ display:none; }
/* —- HOVER ACCORDION (desktop only) —- */
@media (hover:hover) and (pointer:fine){
/* When wrap is hovered: reset default, dim non-hovered */
.rs-ep-wrap:hover .rs-ep-panel.is-default{ flex:1 1 0%; }
.rs-ep-wrap:hover .rs-ep-panel.is-default::after{
opacity:1;
background:linear-gradient(90deg, rgba(0,0,0,.72), rgba(0,0,0,.15));
}
.rs-ep-wrap:hover .rs-ep-panel.is-default .rs-ep-expanded{ display:none; }
.rs-ep-wrap:hover .rs-ep-panel.is-default .rs-ep-collapsed{ display:block; }
/* Hovered panel expands */
.rs-ep-wrap:hover .rs-ep-panel:hover{ flex:3 1 0%; }
.rs-ep-wrap:hover .rs-ep-panel:hover::after{ opacity:0; background:none; }
.rs-ep-wrap:hover .rs-ep-panel:hover .rs-ep-expanded{ display:block; }
.rs-ep-wrap:hover .rs-ep-panel:hover .rs-ep-collapsed{ display:none; }
}
/* —- MOBILE —- */
@media (max-width:650px){
.rs-ep-wrap{
flex-direction:column;
height:auto;
gap:12px;
}
.rs-ep-panel{
height:320px;
flex:none !important;
}
.rs-ep-panel::after{ opacity:0 !important; background:none !important; }
.rs-ep-panel .rs-ep-expanded{
display:flex !important;
flex-direction:column;
}
.rs-ep-panel .rs-ep-kv{
flex:1 1 auto;
display:flex;
flex-direction:column;
justify-content:center;
}
.rs-ep-panel .rs-ep-collapsed{ display:none !important; }
}


.rs-section.rs-card-grid img{display:block;vertical-align:top;max-width:100%;margin:0;padding:0;border:0}
.rs-section.rs-card-grid{background:#f8f8f8;border-radius:15px;padding:50px 20px 75px;box-shadow:0 8px 24px -4px rgba(0,0,0,0.12);font-family:’Arimo’,Arial,sans-serif}
.rs-section.rs-card-grid .ti-wrap{max-width:980px;margin:0 auto}
.rs-section.rs-card-grid .ti-head{text-align:center;margin:0 0 22px}
.rs-section.rs-card-grid .ti-head-title{font-size:30px;font-weight:550;margin:0;color:#111827;font-family:’Poppins’,Arial,sans-serif}
.rs-section.rs-card-grid .ti-head p{margin:10px auto 0;max-width:860px;color:#667085;line-height:1.6}
.rs-section.rs-card-grid .ti-grid{display:grid;gap:18px;grid-template-columns:repeat(2,minmax(0,1fr))}
.rs-section.rs-card-grid .ti-card{background:#ffffff;border:1px solid #e6eaf2;border-radius:12px;box-shadow:0 10px 24px rgba(17,24,39,.06);padding:22px 24px}
.rs-section.rs-card-grid .ti-icon{width:50px;height:50px;border-radius:9px;background:#eef2ff;display:flex;align-items:center;justify-content:center;margin:0 0 12px;overflow:hidden}
.rs-section.rs-card-grid .ti-icon img{width:100%;height:100%;object-fit:cover}
.rs-section.rs-card-grid .ti-title{font-weight:550;color:#111827;margin:0 0 8px;font-family:’Poppins’,Arial,sans-serif}
.rs-section.rs-card-grid .ti-body{margin:0;color:#667085;line-height:1.6}
@media(max-width:768px){.rs-section.rs-card-grid .ti-grid{grid-template-columns:1fr}}
The Hexplorer combines onboard AI, multi-modal perception, and an open software stack to enable advanced autonomous behaviors out of the box, while remaining fully extensible for custom development.

The Hexplorer supports fully autonomous navigation using fused LiDAR and depth camera data for real-time mapping and path planning. Onboard obstacle detection and avoidance algorithms allow the robot to traverse complex environments without operator input.

Ubuntu 22.04 and ROS2 Humble come pre-installed with a full node topology for motion control, sensor data, and system monitoring. Developers can extend the platform using the provided Python and C++ SDKs, CMake build system, and example programs.

The Hexplorer supports human detection and target following using its depth camera and AI compute stack. These capabilities enable interactive and service-oriented deployments such as guided tours, monitoring, and human-alongside operation.

Onboard expansion interfaces include USB Type-C, Ethernet, HDMI, and 19V power outputs, enabling integration of external sensors, computing boxes, and peripherals. Future-ready support for collaborative robotic arms, wireless charging, and long-range video transmission is built into the platform architecture.
.rs-section.rs-staggered-rows img{display:block;vertical-align:top;max-width:100%;margin:0;padding:0;border:0}
.rs-section.rs-staggered-rows{font-family:’Arimo’,Arial,sans-serif}
.rs-section.rs-staggered-rows .inner{max-width:1140px;margin:0 auto;padding:50px 0 50px}
.rs-section.rs-staggered-rows .hero{text-align:center;border-bottom:1px solid rgba(0,0,0,.08);padding:6px 6px 14px;margin:0 0 26px}
.rs-section.rs-staggered-rows .hero .h{font-size:32px;font-weight:550;margin:0;color:#0b1220;font-family:’Poppins’,Arial,sans-serif}
.rs-section.rs-staggered-rows .hero .p{margin:10px auto 0;max-width:980px;color:rgba(11,18,32,.62);line-height:1.5}
.rs-section.rs-staggered-rows .rows{display:flex;flex-direction:column;gap:26px}
.rs-section.rs-staggered-rows .wma-row{display:flex;align-items:center;gap:26px}
.rs-section.rs-staggered-rows .wma-row.rev{flex-direction:row-reverse}
.rs-section.rs-staggered-rows .wma-text{flex:1 1 44%;min-width:0}
.rs-section.rs-staggered-rows .wma-title{display:flex;gap:12px;align-items:flex-start}
.rs-section.rs-staggered-rows .wma-ico{width:28px;height:28px;border-radius:8px;background:#eef2ff;display:inline-block;margin-top:3px}
.rs-section.rs-staggered-rows .wma-h3{font-size:24px;font-weight:550;margin:0;color:#0b1220;line-height:1.15;font-family:’Poppins’,Arial,sans-serif}
.rs-section.rs-staggered-rows .wma-p{margin:10px 0 0;color:rgba(11,18,32,.62);line-height:1.55}
.rs-section.rs-staggered-rows .wma-media{flex:1 1 56%;min-width:0}
.rs-section.rs-staggered-rows .wma-box{border-radius:14px;overflow:hidden;background:#f8f8f8;aspect-ratio:16/9;position:relative;min-height:160px}
.rs-section.rs-staggered-rows .wma-box img{position:absolute;inset:0;width:100%;height:100%;object-fit:cover;object-position:center;display:block;vertical-align:top}
@media(max-width:780px){.rs-section.rs-staggered-rows .wma-row,.rs-section.rs-staggered-rows .wma-row.rev{flex-direction:column!important;gap:16px}.rs-section.rs-staggered-rows .wma-text,.rs-section.rs-staggered-rows .wma-media{flex:1 1 auto;width:100%}}


padding-top:18px;
–inc-bg:#f8f8f8;
–inc-line:rgba(11,18,32,.14);
–inc-txt:#0b1220;
–inc-muted:rgba(11,18,32,.70);
–inc-accent:#00446a;
–inc-radius:15px;
–inc-pad:16px;
–inc-indent:18px;
font-family:’Arimo’,system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
color:var(–inc-txt);
}
.rs-inc, .rs-inc *{ box-sizing:border-box; }
.rs-inc .wrap{
border-radius:var(–inc-radius);
background:var(–inc-bg);
border:0;
box-shadow:0 4px 16px rgba(11,18,32,.08), 0 1px 4px rgba(11,18,32,.06);
overflow:hidden;
padding:var(–inc-pad);
}
.rs-inc .titlebar{
display:flex;
align-items:flex-end;
justify-content:space-between;
gap:12px;
margin:0 0 12px 0;
padding:0 0 10px 0;
border-bottom:1px solid rgba(11,18,32,.10);
}
.rs-inc .title{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-size:18px;
font-weight:550;
color:var(–inc-txt) !important;
letter-spacing:.2px;
}
.rs-inc .badge{
margin:0 !important;
color:var(–inc-muted) !important;
font-weight:500;
font-size:12px;
letter-spacing:.2px;
white-space:nowrap;
}
.rs-inc .badge b{ color:var(–inc-accent); }
.rs-inc .card{
border:1px solid rgba(11,18,32,.14);
border-radius:12px;
background:#ffffff;
padding:12px;
min-width:0;
}
.rs-inc .rowhead{
display:flex;
align-items:center;
gap:10px;
margin:0 0 10px 0;
}
.rs-inc .label{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-weight:600;
letter-spacing:.2px;
text-transform:uppercase;
font-size:12px;
color:rgba(11,18,32,.70) !important;
}
.rs-inc .bul{
width:100%;
border-collapse:collapse !important;
border-spacing:0 !important;
border:0 !important;
margin:0;
box-shadow:none !important;
background-image:none !important;
outline:0 !important;
}
.rs-inc .bul tbody,
.rs-inc .bul tr,
.rs-inc .bul td{
border:0 !important;
box-shadow:none !important;
background-image:none !important;
outline:0 !important;
}
.rs-inc .bul td{
padding:0;
vertical-align:top;
}
.rs-inc .bul .b{
width:var(–inc-indent);
padding-right:10px;
color:rgba(11,18,32,.35);
font-size:14px;
line-height:1.5;
}
.rs-inc .bul .t{
font-size:14px;
font-weight:500;
line-height:1.5;
color:var(–inc-txt);
padding-bottom:6px;
}
.rs-inc .bul tr:last-child .t{ padding-bottom:0; }
.rs-inc .note{
margin:10px 0 0 0;
color:var(–inc-muted);
font-size:12px;
line-height:1.35;
}
@media (max-width: 640px){
.rs-inc .wrap{ padding:14px; }
}
| • | Dobot Hexplorer Six-legged Bionic Robot |
| • | Remote Controller |
| • | Charger |
Package contents vary by configuration.
padding-top:18px;
–dims-bg:#f8f8f8;
–dims-line:rgba(11,18,32,.14);
–dims-txt:#0b1220;
–dims-muted:rgba(11,18,32,.70);
–dims-accent:#00446a;
–dims-radius:15px;
–dims-pad:16px;
–dims-indent:18px;
font-family:’Arimo’,system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
color:var(–dims-txt);
}
.rs-dims, .rs-dims *{ box-sizing:border-box; }
.rs-dims .wrap{
border-radius:var(–dims-radius);
background:var(–dims-bg);
border:0;
box-shadow:0 4px 16px rgba(11,18,32,.08), 0 1px 4px rgba(11,18,32,.06);
overflow:hidden;
padding:var(–dims-pad);
}
.rs-dims .titlebar{
display:flex;
align-items:flex-end;
justify-content:space-between;
gap:12px;
margin:0 0 12px 0;
padding:0 0 10px 0;
border-bottom:1px solid rgba(11,18,32,.10);
}
.rs-dims .title{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-size:18px;
font-weight:550;
color:var(–dims-txt) !important;
letter-spacing:.2px;
}
.rs-dims .badge{
margin:0 !important;
color:var(–dims-muted) !important;
font-weight:500;
font-size:12px;
letter-spacing:.2px;
white-space:nowrap;
}
.rs-dims .badge b{ color:var(–dims-accent); }
.rs-dims .hi{
display:grid;
grid-template-columns:repeat(12,minmax(0,1fr));
gap:10px;
}
.rs-dims .tile{
grid-column:span 6;
border:1px solid rgba(11,18,32,.14);
border-radius:12px;
background:#ffffff;
padding:12px;
min-width:0;
}
.rs-dims .tile b{
display:block;
font-family:’Poppins’,sans-serif;
font-size:12px;
letter-spacing:.2px;
color:rgba(11,18,32,.65);
margin-bottom:8px;
line-height:1.15;
font-weight:600;
text-transform:uppercase;
}
.rs-dims .bul{
width:100%;
border-collapse:collapse !important;
border-spacing:0 !important;
border:0 !important;
margin:0;
box-shadow:none !important;
background-image:none !important;
outline:0 !important;
}
.rs-dims .bul tbody,
.rs-dims .bul tr,
.rs-dims .bul td{
border:0 !important;
box-shadow:none !important;
background-image:none !important;
outline:0 !important;
}
.rs-dims .bul td{
padding:0;
vertical-align:top;
}
.rs-dims .bul .b{
width:var(–dims-indent);
padding-right:10px;
color:rgba(11,18,32,.35);
font-size:14px;
line-height:1.5;
}
.rs-dims .bul .t{
font-size:14px;
font-weight:500;
line-height:1.5;
color:var(–dims-txt);
}
.rs-dims .note{
margin:10px 0 0 0;
color:var(–dims-muted);
font-size:12px;
line-height:1.35;
}
@media (max-width: 640px){
.rs-dims .wrap{ padding:14px; }
.rs-dims .tile{ grid-column:1 / -1; }
}
| • | 86.3 cm x 47 cm x 48 cm |
| • | 73.4 cm x 47 cm x 24.4 cm |
| • | ~20 kg (Robot body) |
| • | 81.5 cm x 54.3 cm x 35 cm |
Values shown are from the manufacturer’s reference.
padding-top:18px;
–links-bg:#f8f8f8;
–links-txt:#0b1220;
–links-muted:rgba(11,18,32,.70);
–links-accent:#00446a;
–links-radius:15px;
–links-pad:16px;
–links-indent:18px;
–links-gap:10px;
font-family:’Arimo’,system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
color:var(–links-txt);
}
.rs-links, .rs-links *{ box-sizing:border-box; }
.rs-links hr{ display:none !important; }
.rs-links .rsln-wrap{
border-radius:var(–links-radius);
background:var(–links-bg);
border:0;
box-shadow:0 4px 16px rgba(11,18,32,.08), 0 1px 4px rgba(11,18,32,.06);
overflow:hidden;
padding:var(–links-pad);
}
.rs-links .rsln-titlebar{
display:flex;
align-items:flex-end;
justify-content:space-between;
gap:12px;
margin:0 0 12px 0;
padding:0 0 10px 0;
border-bottom:1px solid rgba(11,18,32,.10);
}
.rs-links .rsln-title{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-size:18px;
font-weight:550;
color:var(–links-txt) !important;
letter-spacing:.2px;
}
.rs-links .rsln-badge{
margin:0 !important;
color:var(–links-muted) !important;
font-weight:500;
font-size:12px;
letter-spacing:.2px;
white-space:nowrap;
}
.rs-links .rsln-badge b{ color:var(–links-accent); }
.rs-links .rsln-grid{
display:grid;
grid-template-columns:repeat(12,minmax(0,1fr));
gap:10px;
}
.rs-links .rsln-card{
grid-column:span 12;
border:1px solid rgba(11,18,32,.14);
border-radius:12px;
background:#ffffff;
padding:12px;
min-width:0;
}
.rs-links .rsln-head{
margin:0 0 10px 0 !important;
font-family:’Poppins’,sans-serif;
font-weight:600;
letter-spacing:.2px;
text-transform:uppercase;
font-size:12px;
color:rgba(11,18,32,.70) !important;
}
.rs-links .rsln-item{
display:flex;
align-items:flex-start;
gap:var(–links-gap);
margin:6px 0;
padding:0;
}
.rs-links .rsln-item:first-child{ margin-top:0; }
.rs-links .rsln-item:last-child{ margin-bottom:0; }
.rs-links .rsln-bullet{
width:var(–links-indent);
flex:0 0 var(–links-indent);
color:rgba(11,18,32,.35);
font-size:14px;
line-height:1.5;
}
.rs-links .rsln-text{
min-width:0;
font-size:14px;
font-weight:500;
line-height:1.5;
color:var(–links-txt) !important;
overflow-wrap:anywhere;
}
.rs-links .rsln-text a,
.rs-links .rsln-text a:link,
.rs-links .rsln-text a:visited{
display:inline !important;
font-size:inherit !important;
line-height:inherit !important;
font-weight:500 !important;
color:var(–links-txt) !important;
text-decoration:none !important;
text-indent:0 !important;
letter-spacing:normal !important;
white-space:normal !important;
background:none !important;
border:0 !important;
padding:0 !important;
margin:0 !important;
opacity:1 !important;
visibility:visible !important;
overflow:visible !important;
}
.rs-links .rsln-text a:before,
.rs-links .rsln-text a:after{
content:none !important;
}
.rs-links .rsln-text a:hover{
text-decoration:underline !important;
text-underline-offset:2px;
}
.rs-links .rsln-grid,
.rs-links .rsln-card{
background-image:none !important;
box-shadow:none !important;
outline:0 !important;
}
@media (max-width: 640px){
.rs-links .rsln-wrap{ padding:14px; }
}
padding-top:18px;
–spec-bg:#f8f8f8;
–spec-line:rgba(11,18,32,.14);
–spec-txt:#0b1220;
–spec-muted:rgba(11,18,32,.70);
–spec-accent:#00446a;
–spec-radius:15px;
–spec-pad:16px;
font-family:’Arimo’,system-ui,-apple-system,Segoe UI,Roboto,Arial,sans-serif;
color:var(–spec-txt);
}
.rs-spec, .rs-spec *{ box-sizing:border-box; }
.rs-spec .wrap{
border-radius:var(–spec-radius);
background:var(–spec-bg);
border:0; box-shadow:0 4px 16px rgba(11,18,32,.08), 0 1px 4px rgba(11,18,32,.06); overflow:hidden;
padding:var(–spec-pad);
}
.rs-spec .titlebar{
display:flex; align-items:flex-end; justify-content:space-between;
gap:12px; margin:0 0 12px 0; padding:0 0 10px 0;
border-bottom:1px solid rgba(11,18,32,.10);
}
.rs-spec .title{
margin:0 !important;
font-family:’Poppins’,sans-serif;
font-size:18px; font-weight:550;
color:var(–spec-txt) !important;
letter-spacing:.2px;
}
.rs-spec .badge{
margin:0 !important;
color:var(–spec-muted) !important;
font-weight:500; font-size:12px; letter-spacing:.2px; white-space:nowrap;
}
.rs-spec .badge b{ color:var(–spec-accent); }
.rs-spec .rows{ margin-top:0; padding-top:0; }
.rs-spec .row{
display:grid; grid-template-columns:1.2fr .9fr;
gap:14px; padding:10px 0;
border-bottom:1px solid rgba(11,18,32,.08);
}
.rs-spec .row:last-child{ border-bottom:none; }
.rs-spec .k{ font-size:14px; color:var(–spec-muted); font-weight:500; }
.rs-spec .v{ font-size:14px; color:var(–spec-txt); font-weight:500; overflow-wrap:anywhere; }
@media (max-width: 640px){
.rs-spec .wrap{ padding:14px; }
.rs-spec .row{ grid-template-columns:1fr; gap:6px; }
}


Reviews
There are no reviews yet.